


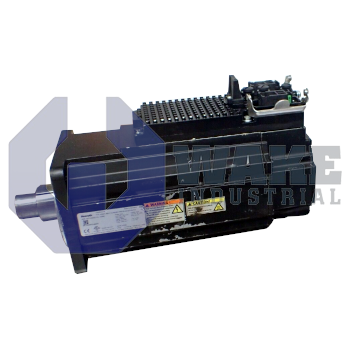
KSM02.1B-061C-35N-M1-HG2-ET-NN-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911342578
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-061C-35N-M1-HG2-ET-NN-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a hybrid connector, natural convection cooling, and operates with a DC 750 V supply voltage. The servo drive includes a Hiperface optical encoder with multi-turn absolute functionality and a holding brake that is electrically released at 24 V DC.
Internal Product Review
The KSM02.1B-061C-35N-M1-HG2-ET-NN-D7-TO-FW is a motor-integrated servo drive configured for Multi-Ethernet communication. Natural convection cooling and a multi-turn absolute encoder make the design especially appealing for stable thermal performance and accurate position handling. The electrically released holding brake with 24 VDC operation is a valuable finishing detail for controlled stopping.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The Bosch Rexroth Indramat KSM02.1B-061C-35N-M1-HG2-ET-NN-D7-TO-FW belongs to the KSM Motor Integrated Servo Drives series and combines the motor, power electronics, and network interface in one housing. Designed for decentralized installation on machine frames, it drives a single rotary axis directly while reducing control cabinet wiring. In packaging lines, material-handling systems, and compact assembly cells, the unit provides closed-loop speed and position control so the higher-level PLC sends motion commands instead of phase currents.
The unit is version 1 in series 2 and accepts DC 750 V bus power through a single Hybrid Connector that carries power, logic, and protective earth. Heat is removed by natural convection, which eliminates fans and keeps the housing layout simple. Axis feedback uses the Hiperface protocol, and the optical sensor provides 128 signal periods per mechanical turn while storing multi-turn absolute position data without batteries. An electrically released holding brake clamps the shaft when control power is removed, which helps prevent back-driving on vertical loads. Winding code 35 identifies the electrical setup used for this motor section, and the unit is supplied without integrated safety technology.
Network communication is handled through Multi-Ethernet, which supports common industrial Ethernet protocols through the same interface. Brake release is powered by DC 24 V. Torque is transmitted through a plain shaft with a shaft seal, which supports use in splash-prone areas. The mechanical envelope uses frame size 061 with length C, and the basic performance level is intended for standard duty cycles that require moderate dynamic response and continuous torque. This layout supports direct machine mounting without the need for a separate motor and drive combination.









