


KSM02.1B-061C-35N-M1-HG0-ET-S3-D7-ES-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911369198
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
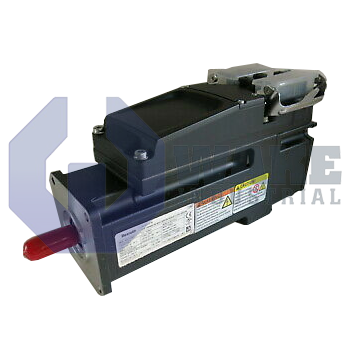
The Bosch Rexroth Indramat KSM02.1B-061C-35N-M1-HG0-ET-S3-D7-ES-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a hybrid connector, operates with a supply voltage of DC 750 V, and uses natural convection cooling. This unit is equipped with optical Hiperface encoder technology that provides 128 signal periods and a multi-turn absolute encoder.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-061C-35N-M1-HG0-ET-S3-D7-ES-FW belongs to the KSM Motor Integrated Servo Drives series developed by Bosch Rexroth Indramat. As a motor-integrated servo drive, it combines the servomotor, power electronics, and feedback in one housing so it can mount directly on the machine frame and drive decentralized axes in automated production lines. This arrangement reduces cabinet space and simplifies wiring by placing the drive near the load, making it suitable for packaging, material handling, and assembly stations that need synchronized motion under distributed control. The integrated layout is also useful on moving machine sections where long motor cables are less practical.
It uses a DC bus supply of DC 750 V, allowing connection to shared power rails in multi-axis systems. Heat generated by the electronics is removed through natural convection, so no forced-air components or coolant hookups are required. A single Hybrid Connector carries power, safety I/O, and communication, which helps reduce cable runs. Rotor position and multi-turn angle are returned through a Hiperface optical encoder that provides 128 signal periods per revolution for drive regulation. The axis is supplied without a holding brake, so mechanical clamping or drive torque must secure vertical loads when power is removed. The feedback arrangement supports accurate motion control during positioning and speed-regulated operation.
For supervisory control, the integrated interface supports Multi-Ethernet protocols, allowing the unit to work with different real-time Ethernet networks used in automated systems. Functional safety is handled inside the unit through Safe Motion (without SBC) features that monitor position and speed locally and trigger shutdown when limits are exceeded. The servo fits machines with limited installation depth because of its 061 frame size and C-length stator. It also uses a plain shaft and an internal shaft seal, which help protect the bearings from contamination during normal machine operation.









