


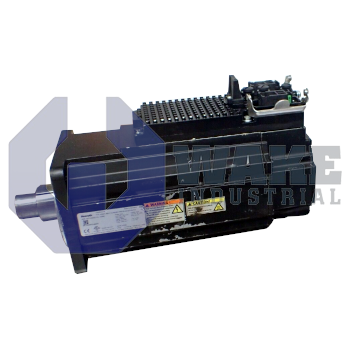
KSM02.1B-041C-42N-S1-HG2-ET-NN-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911389457
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-041C-42N-S1-HG2-ET-NN-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. This device features a hybrid connector, supports Multi-Ethernet output coupling, and has a supply voltage of DC 750 V. It uses a Hiperface optical single-turn encoder and is cooled by natural convection.
Internal Product Review
The KSM02.1B-041C-42N-S1-HG2-ET-NN-D7-TO-FW is a motor-integrated servo drive that stands out with natural convection cooling and Multi-Ethernet communication. The Hiperface encoder interface and electrically released holding brake support precise motion control and dependable axis management. A very practical servo package for compact automation cells, especially where integrated drive architecture simplifies installation.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-S1-HG2-ET-NN-D7-TO-FW is a motor-integrated servo drive built by Bosch Rexroth Indramat within the KSM Motor Integrated Servo Drives series. By combining the servo motor, power electronics, and networking hardware in one housing, the unit provides decentralized axis control for packaging, material handling, and general automation where panel space is limited. This layout removes the need for a separate cabinet-mounted inverter and reduces the amount of field wiring between the drive and motor. It is suited to decentralized machine sections where compact axis modules are mounted close to conveyors, transfer units, or handling mechanisms.
It draws its DC 750 V link voltage from a shared bus, so the integrated inverter can operate with other IndraDrive modules on a common supply. Power, signal, and brake conductors are combined in a single Hybrid Connector, which supports compact cable routing across multiple axes and reduces the number of separate cable entries. Heat is removed by natural convection, so no fans or liquid circuits are required. Position feedback is transmitted through a Hiperface interface, and the encoder uses optical scanning with a single-turn design, so the drive receives commutation and position data through one feedback path. The motor uses frame size 041 with length code C, and winding code 42 sets the electromagnetic values for mid-range torque. The unit is design version 1 in series 2.
The mechanical section includes an electrically released holding brake that locks the rotor when control power is absent, and it is energized with DC 24 V during commanded motion. Encoder resolution reaches 128 signal periods, which supports accurate interpolation during contouring tasks. Host communication is handled over Multi-Ethernet, allowing network protocol selection through software to match plant control architectures. The output uses a plain shaft with a shaft seal, which supports coupling to belt pulleys or planetary gearboxes while helping keep lubricants contained. The unit has a Basic performance level.









