


KSM02.1B-041C-42N-M3-HP0-ET-NN-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911381147
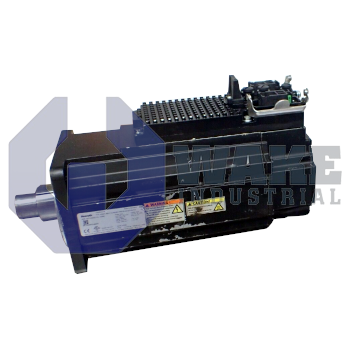
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-041C-42N-M3-HP0-ET-NN-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It uses a hybrid connector for connection, features a shaft with keyway and a capacitive Hiperface multi-turn absolute encoder, and operates with natural convection cooling. This drive supports Multi-Ethernet communication, has a supply voltage of DC 750 V, and does not include a holding brake or safety technology.
Internal Product Review
The KSM02.1B-041C-42N-M3-HP0-ET-NN-D7-TO-FW is a Bosch Rexroth motor-integrated servo drive designed for DC 750 V operation. Multi-Ethernet master communication and Multi-Ethernet output coupling support efficient network integration in distributed motion systems. The Hiperface multi-turn absolute encoder provides dependable feedback, making the unit a strong choice for streamlined servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
Bosch Rexroth Indramat builds the KSM02.1B-041C-42N-M3-HP0-ET-NN-D7-TO-FW as a motor-integrated servo drive within the KSM Motor Integrated Servo Drives series. By combining the motor, encoder, and drive electronics in one housing, the unit simplifies wiring on distributed axes used for packaging, printing, or material-handling cells. It operates as a decentralized drive module that accepts DC bus power and returns position data to the controller over real-time fieldbus networks, reducing cabinet space and cable runs in industrial automation.
The single-cable power and feedback line terminates through a Hybrid Connector, so installation requires only one routed line instead of separate motor and resolver leads. Heat is removed solely by natural convection, so the drive must be mounted where vertical airflow is unobstructed. Position information is generated by a Hiperface encoder interface that delivers absolute data over 16 signal periods, supporting fine interpolation in the motion controller. The internal electronics are supplied from a shared DC link rated at DC 750 V, allowing the module to return energy from decelerating loads to the supply. The unit uses Multi-Ethernet for communication, letting the same hardware connect to EtherNet/IP, PROFINET, or EtherCAT. The drive is delivered without a holding brake and has no integrated safety technology, so external devices must handle static load retention and safety functions.
Absolute position retention over multiple revolutions is possible because the sensing element is a Multi-turn absolute system that counts turns even while power is removed. Its measuring principle is capacitive, which helps it resist magnetic fields and vibration. The electromechanical core corresponds to motor size 041, while winding code 42 tailors the torque constant and rated speed for basic performance duty. A shaft seal is fitted, and the output end is machined as a shaft with keyway, permitting direct coupling to pulleys or gearboxes without additional adapters.









