


KSM02.1B-041C-42N-M3-HG2-ET-L3-D7-NN-FW Bosch Rexroth Indramat
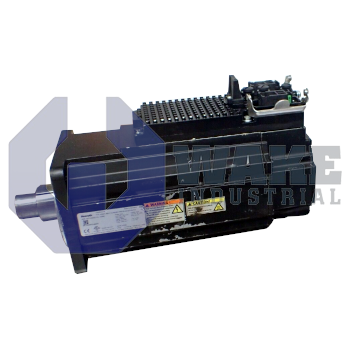
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911341443
The Bosch Rexroth Indramat KSM02.1B-041C-42N-M3-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features Multi-Ethernet master communication, a Hiperface capacitive multi-turn absolute encoder, and Safe Torque Off safety technology. The drive includes a hybrid connector, operates with a DC 750 V supply voltage, and uses natural convection for cooling.
Internal Product Review
The KSM02.1B-041C-42N-M3-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive with Multi-Ethernet communication. Natural convection cooling and Safe Torque Off support make the design especially appealing for clean machine integration and dependable operation. A capacitive encoder with Hiperface interface adds solid feedback performance, making the drive a strong choice for integrated servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-M3-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It combines drive electronics with a 041 frame-size servo motor, allowing decentralized motion control on machines that use compact axis nodes instead of large control cabinets. As a Basic performance device, it provides torque from its C-length stator section while supporting Safe Torque Off to remove drive energy during hazardous stop events. The integrated format places the power stage close to the axis, which shortens motor cable runs and helps distributed layouts stay compact.
A single Hybrid Connector carries DC power, control signals, and brake supply, reducing panel space requirements and simplifying cable routing. Heat generated by the electronics leaves the housing through natural convection, so no cooling fan is required. Position feedback comes from a Hiperface interface that exchanges absolute data with the controller; its scale provides 16 signal periods per mechanical revolution, and the underlying sensing method is the Capacitive technique, which is resistant to magnetic stray fields. The standard mechanical arrangement uses a plain shaft, and a shaft seal limits fluid ingress when the axis is exposed to process splash. Motor characteristics are set by winding code 42.
The encoder delivers a Multi-turn absolute position value, so machine homing is unnecessary after power cycles. Holding force is supplied by an electrically released brake that engages when its coil loses its DC 24 V supply. Command and diagnostic traffic reach the drive over Multi-Ethernet, allowing operation on several deterministic field networks without hardware changes. The internal inverter draws bus energy from a DC 750 V supply for the integrated power stage.









