


KSM02.1B-041C-42N-M3-HG0-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911337228
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
3 Minutes
51 Seconds
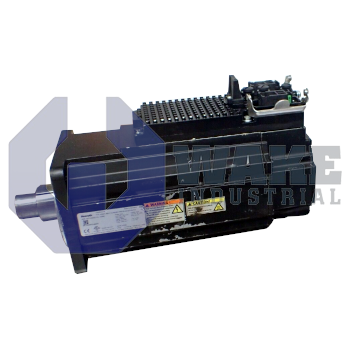
The Bosch Rexroth Indramat KSM02.1B-041C-42N-M3-HG0-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It uses a hybrid connector and operates with natural convection cooling, while supporting a supply voltage of DC 750 V. The drive features a capacitive multi-turn absolute encoder with Hiperface interface and 16 signal periods of resolution.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-M3-HG0-ET-NN-D7-NN-FW is a motor-integrated servo drive built by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It combines a synchronous motor and drive controller in one housing, so it can be mounted directly on moving machine axes instead of using a separate cabinet-mounted amplifier. This layout saves cabinet space, shortens motor leads, and simplifies wiring in industrial automation lines that use decentralized motion control. It also uses a plain shaft with a factory-installed seal that helps keep lubricants inside the gearbox while limiting splash and dust entry.
This unit is fed from a DC 750 V power bus, so it can be daisy-chained with other drives on the same high-voltage DC link. Heat produced by the electronics and stator is removed through natural convection, so mounting must allow unobstructed airflow around the housing during operation. Power, feedback, and communication lines are consolidated in a single Hybrid Connector, reducing cable bulk along energy chains and leaving fewer separate connections at the axis. Command data reach the drive over the Multi-Ethernet interface, allowing use with several Ethernet-based fieldbus systems without hardware changes. This model has the Basic performance level, which suits standard positioning and handling tasks.
Position feedback is gathered through a Hiperface encoder that uses 16 signal periods per mechanical revolution and multi-turn absolute counting, allowing the controller to report shaft angle after power loss without a homing move. The sensing element is a capacitive system, so it tolerates oil mist and magnetic fields better than optical disks. The drive is supplied without a holding brake, so applications that must remain fixed during power-down need an external clamp. Integrated safety functions are not included, so safety-related stopping and monitoring must be handled by external controllers.









