


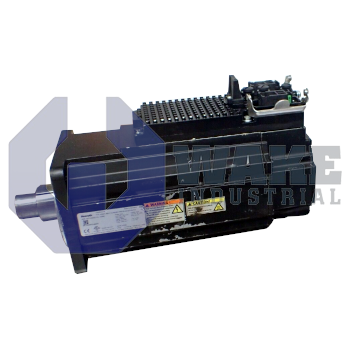
KSM02.1B-041C-42N-M1-HP0-ET-S3-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911375970
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-041C-42N-M1-HP0-ET-S3-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a DC 750 V supply voltage, natural convection cooling, and a hybrid connector type. The servo drive is equipped with a Hiperface optical encoder with multi-turn absolute capability and supports multi-Ethernet output coupling.
Internal Product Review
The KSM02.1B-041C-42N-M1-HP0-ET-S3-D7-TO-FW is a Bosch Rexroth motor-integrated servo drive with natural convection cooling. Multi-Ethernet master communication and output coupling make network integration efficient in distributed motion architectures. The optical multi-turn absolute encoder supports dependable position feedback, a strong feature for precise servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-M1-HP0-ET-S3-D7-TO-FW is a motor-integrated servo drive manufactured by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. This device merges a permanent-magnet servo motor, power electronics, and a fieldbus interface in one housing. It enables decentralized motion control on machines that require compact installation and simplified cabling. By integrating these functions at the machine, the unit reduces the need for separate motor and drive packaging inside the control cabinet.
The drive is supplied from a DC 750 V intermediate circuit and receives power, signal, and service lines through a single Hybrid Connector. Heat is removed by natural convection, so no fans or liquid channels are required. The unit uses Multi-Ethernet output coupling, which supports EtherNet/IP, PROFINET, and EtherCAT on the same hardware. This allows the same platform to fit different real-time Ethernet control systems without changing the integrated drive concept. Motion functions run at the Basic performance level, and Safe Motion without SBC is available for STO and SS1 functions. The motor section follows size code 041 and pairs with length code C. The motor has a keyway shaft with a shaft seal, and because the unit is supplied without a holding brake, external means must secure vertical axes when power is removed.
Position feedback is handled through a Hiperface interface that links the drive to an optical encoder delivering 128 signal periods per revolution. Multi-turn tracking is available up to 4096 revolutions because the sensing element is a Multi-turn absolute type. This feedback arrangement lets the controller retain position information across repeated revolutions while supporting accurate rotor tracking during operation. The optical measuring principle provides high repeatability and immunity to magnetic stray fields. Winding code 42 corresponds to the current constant used by the integrated controller to linearize torque output during dynamic load changes. Design version 1 and internal series number 2 identify this model within the product line.









