


KSM02.1B-041C-42N-M1-HG2-ET-S3-D7-ES-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911370432
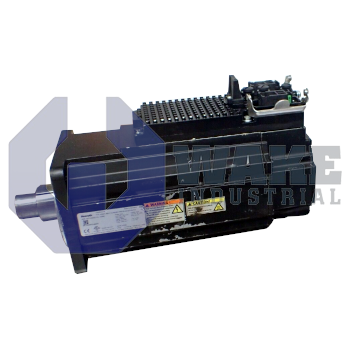
The Bosch Rexroth Indramat KSM02.1B-041C-42N-M1-HG2-ET-S3-D7-ES-FW is a motor-integrated servo drive in the KSM Motor Integrated Servo Drives series. It features Multi-Ethernet master communication, an optical Hiperface multi-turn absolute encoder with 128 signal periods, and operates on a DC 750 V supply voltage. The unit uses natural convection cooling and includes an electrically released holding brake at 24 V DC.
Internal Product Review
The KSM02.1B-041C-42N-M1-HG2-ET-S3-D7-ES-FW is a well-engineered motor-integrated servo drive with natural convection cooling. Multi-Ethernet master communication and a Hiperface encoder interface support streamlined integration and stable feedback in motion systems. An electrically released 24 V holding brake adds valuable control security for demanding servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-M1-HG2-ET-S3-D7-ES-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat as part of the KSM Motor Integrated Servo Drives series. By combining a permanent-magnet servomotor, encoder, and power electronics within one housing, the unit simplifies decentralized motion axes on machines. It positions tooling, conveyor segments, or robotic joints with closed-loop accuracy while minimizing cabinet wiring. This layout places the drive functions directly at the axis, which helps simplify machine architecture and reduce the distance between power conversion and feedback sensing. Design version 1 belongs to series 2 and uses motor size 041 with length code C for packaging, assembly, and material-handling applications.
The drive electronics accept a nominal bus voltage of DC 750 V, allowing it to share a common DC link with other inverters on the machine. All power, feedback, and fieldbus lines are combined in a Hybrid Connector, so installation requires only one plug at the motor. Using one connector also helps organize cable routing in compact machine modules where space around the axis is limited. Heat generated by the controller is removed through natural convection, so the housing does not require fan-assisted cooling. Position feedback is delivered through a Hiperface optical sensor that provides 128 signal periods per mechanical revolution, and the integrated multi-turn absolute track preserves true position information after a power cycle. Multi-Ethernet capability is provided through the external master communication option, enabling protocol selection such as EtherNet/IP or PROFINET.
The mechanical interface uses a plain shaft with a factory-installed shaft seal for ingress protection. The sealed shaft end supports use in areas where splash or light contamination may be present around the drive train. An electrically released holding brake engages automatically when power is removed, and it is energized with DC 24 V. Functional safety is covered by the Safe Motion option without an integrated safety brake control. Classified as the Basic performance level, the unit is suited to standard motion tasks that need secure holding and responsive start-stop behavior.









