


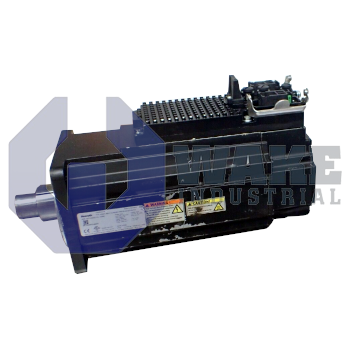
KSM02.1B-041C-42N-M1-HG2-ET-NN-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911335838
The Bosch Rexroth Indramat KSM02.1B-041C-42N-M1-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a hybrid connector connection, natural convection cooling, and Multi-Ethernet master communication protocol. The servo drive is equipped with a Hiperface multi-turn absolute optical encoder and operates at a supply voltage of DC 750 V.
Internal Product Review
The KSM02.1B-041C-42N-M1-HG2-ET-NN-D7-NN-FW is a well-engineered motor-integrated servo drive with Multi-Ethernet communication that fits demanding automation platforms very well. Natural convection cooling and a hybrid connector support streamlined installation and dependable operation. The optical Hiperface encoder stands out for accurate feedback and stable axis control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-M1-HG2-ET-NN-D7-NN-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat as part of the KSM Motor Integrated Servo Drives series. It combines a permanent-magnet servomotor with embedded power electronics, giving the axis torque production, feedback handling, and network connectivity in one enclosure. The unit is intended for decentralized motion axes on material-handling lines, pick-and-place gantries, and light assembly cells, where it reduces cabinet wiring and simplifies setup. Its basic performance level is suited to moderate load cycles common in auxiliary packaging or indexing stations.
The unit accepts a supply bus of DC 750 V, routed through a Hybrid Connector that carries power, signal, and protective earth in a single plug. Cooling relies on Natural convection, so no forced-air components are required when the drive is mounted on an open machine frame. Network traffic for parameter setting and cyclic control is handled through Multi-Ethernet, allowing automatic selection among EtherNet/IP, PROFINET, or EtherCAT at power-up. The motor uses frame size 041 with length C and winding code 42, and the holding brake is energized by DC 24 V to clamp the shaft during standby or emergency stops.
Position feedback is supplied by an optical encoder that uses the Hiperface digital interface. The sensor delivers 128 signal periods per motor revolution and stores multi-turn data by means of a battery-free counting gear, providing Multi-turn absolute position information to the controller after every power cycle. Its Optical scanning principle avoids magnetic offset errors and supports the drive’s basic performance profile. The device does not include integrated safety technology. The shaft seal helps preserve ingress protection when the motor is coupled to external mechanics.









