


KSM02.1B-041C-42N-M1-HG2-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911334434
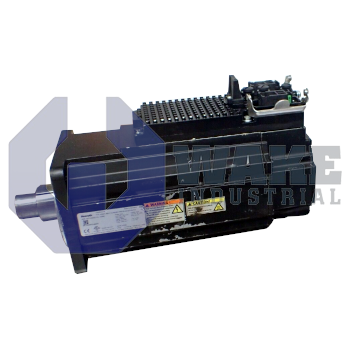
The Bosch Rexroth Indramat KSM02.1B-041C-42N-M1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series featuring a hybrid connector and natural convection cooling. It supports Multi-Ethernet communication and uses an optical Hiperface encoder with multi-turn absolute technology and a resolution of 128 signal periods. The servo drive operates on a supply voltage of DC 750 V and includes Safe Torque Off safety technology.
Internal Product Review
The KSM02.1B-041C-42N-M1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive with Multi-Ethernet communication. Natural convection cooling and Safe Torque Off (STO) support dependable operation in modern machine designs. An electrically released 24 VDC holding brake stands out as a valuable feature for controlled stopping.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-M1-HG2-ET-L3-D7-NN-FW is a motor-integrated servo drive from Bosch Rexroth Indramat in the KSM Motor Integrated Servo Drives series. By combining the power stage, control electronics, and servo motor in one enclosure, it supports decentralized axis control on machines that benefit from reduced cabinet wiring. The unit is series 2 with a Basic performance level, making it suitable for standard positioning and velocity control where precise feedback is required. Its integrated layout also reduces the amount of separate drive hardware that would otherwise be mounted in the cabinet.
The drive operates from a DC 750 V bus, allowing it to share energy with other axes on a common DC link. Heat is removed by natural convection, so no fans or liquid circuits are required when mounting clearances allow vertical airflow. All power, signal, and safety conductors enter through a single Hybrid Connector, which keeps cabling compact and organized. For networked control, the master interface supports Multi-Ethernet and can work with EtherNet/IP, PROFINET, EtherCAT, or Sercos III. Rotor position is measured through a Hiperface optical encoder that provides reliable feedback for closed-loop operation. The motor uses size 041, length C, and winding code 42. The output uses a plain shaft with a shaft seal, and the unit is built in design version 1.
Functional safety is provided by Safe Torque Off (STO), which removes drive energy without changing the fieldbus state. Position feedback provides 128 signal periods per mechanical revolution, and the encoder stores turns through its Multi-turn absolute capability so the axis can retain position information after power cycles. An electrically released brake operates at DC 24 V and holds the load when power is removed. This arrangement supports axes that need both retained position data and load holding during shutdown.









