


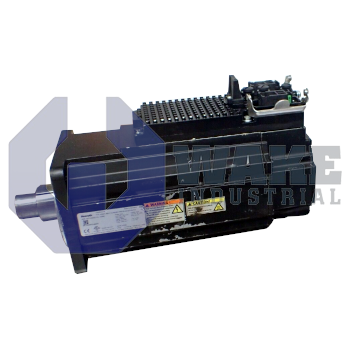
KSM02.1B-041C-42N-M1-HG0-ET-SD-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911391825
Ask for AvailabilityThe Bosch Rexroth Indramat KSM02.1B-041C-42N-M1-HG0-ET-SD-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a 041 size, C length motor, and operates with a supply voltage of DC 750 V. The unit has a hybrid connector, supports Multi-Ethernet communication, and uses an optical multiturn absolute encoder with Hiperface interface.
Internal Product Review
The KSM02.1B-041C-42N-M1-HG0-ET-SD-D7-TO-FW is a motor-integrated servo drive with Multi-Ethernet communication and a DC 750 V supply. Natural convection cooling and Safe Motion with SBC make this unit especially appealing for clean machine integration and dependable operation. The Hiperface multi-turn absolute encoder is a standout feature for precise servo feedback.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-M1-HG0-ET-SD-D7-TO-FW is a motor-integrated servo drive built by Bosch Rexroth Indramat for the KSM Motor Integrated Servo Drives series. It combines a size 041 permanent-magnet motor, an inverter, and decentralized safety in a single housing, so it can be mounted directly on moving axes instead of placing separate inverter hardware in a control cabinet. Because the power electronics are integrated with the motor, power conversion and motion feedback handling occur at the axis itself. The device supports distributed motion tasks in packaging, printing, and handling equipment while keeping network cabling short and the overall machine footprint compact.
The drive draws power from a DC 750 V bus and distributes it internally through a winding code 42 stator used in the series 2 platform. Power, signal, and protective earth conductors terminate on a single Hybrid connector, which keeps the main electrical connections in one location on the housing and reduces the number of separate plugs. Heat is removed through natural convection, eliminating fans and related service parts. Rotor position is reported through a Hiperface interface, and the feedback unit uses an Optical scanning method for fine signal acquisition.
The encoder stores absolute angle data over multiple turns through its Multi-turn absolute design, which supports retained position information after repeated rotation. Functional safety is integrated as Safe Motion (with SBC), providing stop and monitoring functions within the drive package. Torque is transferred through a plain shaft, and ingress of dust or emulsions is limited by a shaft seal. The Multi-Ethernet design option allows the master communication protocol to switch among PROFINET, EtherNet/IP, or SERCOS III. The motor has length C, design version 1, and no holding brake, so holding torque at standstill must be supplied by the drive or by external machine mechanics.









