


KSM02.1B-041C-42N-M1-HG0-ET-L3-D7-TO-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911336246
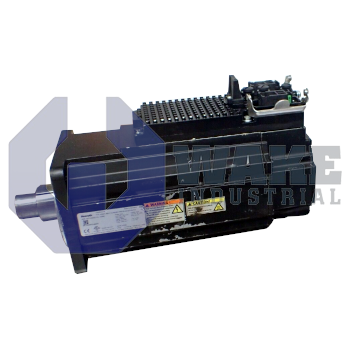
The Bosch Rexroth Indramat KSM02.1B-041C-42N-M1-HG0-ET-L3-D7-TO-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series with a motor size of 041 and natural convection cooling. It offers multi-Ethernet output coupling, has a Hiperface optical encoder with 128 signal periods, and supports Safe Torque Off safety technology. The servo drive operates at a supply voltage of DC 750 V and features a hybrid connector for connection.
Internal Product Review
The KSM02.1B-041C-42N-M1-HG0-ET-L3-D7-TO-FW is a motor-integrated servo drive with natural convection cooling. Multi-Ethernet communication and Safe Torque Off support give the unit strong appeal for efficient machine integration and dependable operation. Hiperface feedback and a hybrid connector round out a well-engineered servo package.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-M1-HG0-ET-L3-D7-TO-FW is a motor-integrated servo drive produced by Bosch Rexroth Indramat and assigned to the KSM Motor Integrated Servo Drives series. By combining drive electronics and a permanent-magnet servomotor in one housing, this unit reduces control-cabinet wiring and supports decentralized motion axes in packaging machines, printing presses, and material-handling cells where compact distributed drive placement is useful. Motion commands are exchanged over the Multi-Ethernet interface, which supports several real-time protocols through one port.
This drive operates on a bus voltage of DC 750 V, allowing it to share a common DC link with other in-line devices. Heat is removed solely through natural convection; no active fan is installed, so the enclosure stays closed and maintenance demands remain low. The single-cable power and signal interface is a Hybrid Connector, which carries the DC supply, safety lines, and Ethernet communication to minimize cable runs. Rotor position is returned via a Hiperface interface, and the optical encoder delivers 128 signal periods per revolution, giving the controller sufficient feedback resolution for precise velocity and position loops under the unit’s basic performance level.
Functional safety is implemented through Safe Torque Off (STO), which disables power stages without affecting fieldbus communication when a stop command is issued. The motor section follows size code 041 with length C, yielding a compact form factor that fits tightly spaced axis arrays. The encoder has a multi-turn absolute capability, so position feedback is retained over power cycles. The shaft is plain and sealed, and the module is supplied without a holding brake, so external mechanics or drive torque must secure vertical loads when power is removed.









