


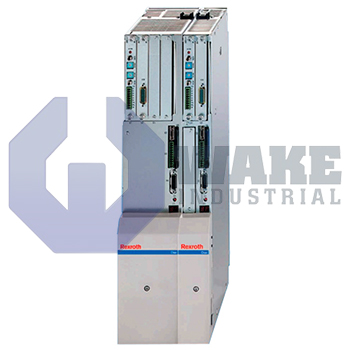
HDS03.2-W100N-HT02-01-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
The Bosch Rexroth Indramat HDS03.2-W100N-HT02-01-FW is part of the HDS Drive Controllers series and belongs to the DIAX04 controller family. This drive controller features a SERCOS command communication interface and a built-in internal air blower for cooling. It supports a rated current of 100 Amps.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The HDS03.2-W100N-HT02-01-FW is a modular drive controller produced by Bosch Rexroth Indramat within the HDS Drive Controllers series. Installed in a DIAX04 multiaxis rack, it converts DC bus energy into precisely regulated three-phase outputs that energize servo and spindle motors during synchronized motion tasks. By executing high-speed current loops and monitoring motor feedback, the unit supports coordinated acceleration profiles and repeatable positioning in packaging lines, printing presses, and material-handling gantries where multiple axes must respond together. It occupies a single rack slot and communicates with the motion processor through a fiber-optic command link.
Its command interface uses the SERCOS ring, providing deterministic telegram timing for axis coordination. Continuous output capability reaches 100 A, allowing the controller to drive high-torque motors without external boosters. Thermal management relies on a built-in air blower that circulates cabinet air across the heat sink and ejects it at the top edge. Mechanical layout and backplane connectors follow the DIAX04 family standard, so the unit slides into existing racks without wiring changes. The control electronics are listed as Version 2, indicating second-generation signal processing with broader diagnostic coverage.
The module is part of Line 03 in the product range, which marks its design line within this controller family. The device remains categorized as an HDS Drive Controller, so primary current regulation is handled locally inside the unit while position loops remain in the higher-level master. This arrangement allows the controller to concentrate on fast electrical response and motor feedback processing while the central motion processor handles axis-level coordination and trajectory control.









