


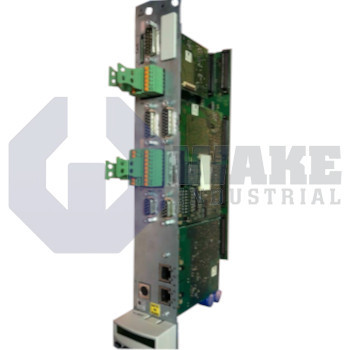
CDB01.1C-S3-EN1-EN1-NNN-MEM-NN-S-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911337860
The Bosch Rexroth Indramat CDB01.1C-S3-EN1-EN1-NNN-MEM-NN-S-NN-FW is a control unit in the CDB Control Units series, supporting two axes and two encoder interfaces for resolver and HSF. It is compatible with SERCOS III communication and offers 100Base-TX network compatibility using an RJ-45 port. The unit provides analog output of 1 mA or 5 V and supports relay contact ratings of 24 V DC at 1 A.
Internal Product Review
The CDB01.1C-S3-EN1-EN1-NNN-MEM-NN-S-NN-FW is a Bosch Rexroth Indramat CDB control unit with SERCOS III communication and 2-axis capability. Dual encoder interfaces with resolver and HSF support give this unit strong flexibility for motion systems that require precise feedback integration. MEM output performance up to 1 MHz is a standout advantage for demanding control applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The CDB01.1C-S3-EN1-EN1-NNN-MEM-NN-S-NN-FW control unit is produced by Bosch Rexroth Indramat within the CDB Control Units series. This card plugs into an IndraDrive power section and coordinates two servo axes, translating motion commands from a PLC into drive-level signals for industrial automation tasks such as packaging, handling, or machining. It serves as the motion-control layer inside the drive assembly, so command processing and axis coordination remain integrated with the power electronics rather than being handled by a separate external module.
For local command issuance, the unit provides an analog output channel that sources up to 1 mA, and the same channel can swing to 5 V for proportional speed or torque references. The controller supervises 2 coordinated axes and exchanges cyclic setpoints via SERCOS III, which supports deterministic communication between the PLC and the drive. Two feedback ports accept resolver and HSF encoders, and both ports are energized by 8 V DC to power the sensors directly. When virtual feedback is required, an internal generator delivers incremental or SSI emulation so downstream devices receive position information without additional hardware. This arrangement allows the control unit to work with both physical motor feedback and simulated position signals in mixed automation systems.
Parameter cloning and update functions use the MEM interface, whose flat cable may extend to 40 m. That channel drives a differential pair capable of 20 mA, and it clocks at 1 MHz to move diagnostic snapshots in real time. Remote monitoring is available over a 100Base-TX link that follows IEEE 802.3u and terminates on an RJ-45, 8-pin connector. A Form C relay with contacts rated at 24 V DC, 1 A allows safety interlocks to remove drive enable under fault conditions. The resolver reference signal is generated at 18.2 Vpp and 4 kHz to maintain clean sine and cosine waveforms for angle decoding. These service and interface functions support data access, fault handling, and stable feedback processing within the same control unit.









