


PMB33F-10216-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
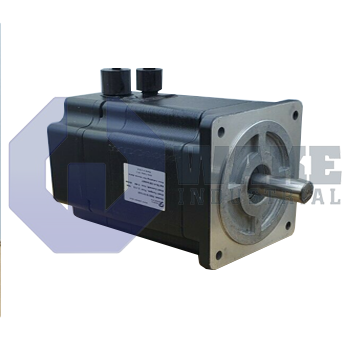
The Pacific Scientific PMB33F-10216-01 is a brushless servomotor from the PMB Brushless Servomotors series. This NEMA Size 34 motor features a digital encoder with commutation and a resolution of 4096 pulses per revolution. It includes flying leads with MS connectors and has a round shaft design with a shaft seal.
Internal Product Review
The PMB33F-10216-01 is a Pacific Scientific PMB Series brushless servomotor designed for precise motion control. A digital encoder with commutation and 4096 ppr resolution support accurate feedback and stable servo response. Flying leads with MS connectors and a shaft seal add practical installation value, making this unit a strong choice for demanding machinery.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The Pacific Scientific PMB33F-10216-01 is a brushless servo motor built within the PMB Brushless Servomotors series. Pacific Scientific supplies this model for closed-loop industrial axes where space is limited yet precise torque is required. By combining a permanent-magnet rotor with electronic commutation, the unit converts command signals from a servo drive into repeatable angular motion for pick-and-place heads, indexing tables, and compact gantry slides. Its operating concept supports accurate starts, stops, and direction changes in automated motion systems.
Mechanical integration is simplified by the NEMA size 34 frame, which provides a 3.4-inch square mounting face and a standard pilot to match many legacy stepper brackets. Power and feedback conductors leave the housing as flying leads with MS connectors, delivering a keyed, environmentally sealed interface that withstands vibration. Rotary position is monitored by an internal encoder producing 4096 ppr, giving the controller fine resolution for velocity loops and small position corrections. Because the sensing element is a digital encoder with commutation, phase information for the stator is delivered through the same channel, which improves low-speed control. During worst-case stall at a 240 VAC bus, the winding demands 11.0 ARMS, a value the drive must supply continuously without triggering thermal rollback.
The motor ships with a round output shaft, enabling direct clamp-coupler engagement without keyway machining. A protective shaft seal surrounds this interface to limit the ingress of fluids and fine dust, which helps preserve bearing life in washdown or oil-mist areas. Magnet stack construction follows length code 3, increasing torque capacity over shorter bodies while preserving the same bolt circle. The longer body gives the motor more active magnetic length without changing the basic mounting format, which is useful where frame compatibility matters.









