


PMB33F-10216-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
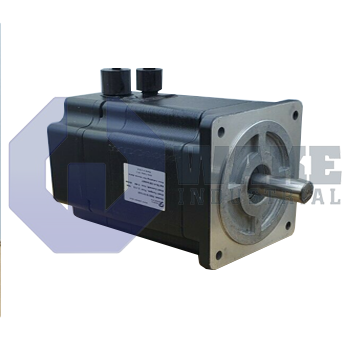
The Pacific Scientific PMB33F-10216-00 is a standard motor from the PMB Brushless Servomotors series, featuring a NEMA Size 34 body and round shaft design. This servomotor uses a digital encoder with commutation and supports an encoder resolution of 4096 pulses per revolution. It comes equipped with flying leads and MS connectors and has a nominal stall current of 11.0 ARMS at 240 VAC max.
Internal Product Review
The PMB33F-10216-00 is a Pacific Scientific PMB Series brushless servomotor in a NEMA Size 34 frame. Digital encoder commutation and 4096 ppr feedback support clean positioning response and stable speed control. Flying leads with MS connectors simplify integration, making the motor a strong choice for servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-10216-00 brushless servomotor is produced by Pacific Scientific for the PMB Brushless Servomotors series. It supplies closed-loop torque and velocity to rotary axes in automated assembly cells, conveyors, and indexing tables. When paired with a matching servo drive, the motor delivers rapid acceleration, repeatable positioning, and bidirectional motion without mechanical brushes. Its NEMA-conforming frame integrates with common gearheads and mounting brackets on modular machine platforms.
Its frame follows the NEMA Size 34 envelope, so the front face measures 3.4 inches square and aligns with widely available clamps and adapter plates. Under a 240 VAC bus, the windings can sustain a nominal stall current of 11.0 ARMS, and this continuous rating sets the thermal limit for amplifier selection and cooling. Position feedback comes from a quadrature encoder that delivers 4096 ppr, enabling high-resolution motion profiles and tight servo loops. Power, signal, and protective earth conductors exit as flying leads terminated in rugged MS connectors, allowing secure connection to compatible system cabling. The feedback assembly uses a digital encoder with commutation, so electrical phase information is carried in the same device and start-up alignment is simplified.
Because the unit is supplied as a standard motor, its electrical characteristics follow the standard configuration for this model. The output shaft is round, which permits direct coupling with rigid or flexible clamps without concern for keyway orientation. A stator stack-length multiple of 3 increases continuous torque density while keeping the outside dimensions unchanged, which helps manage the heat produced at nominal stall. As a PMB Series Brushless Servomotor, it is intended for closed-loop motion systems that use compatible encoder feedback and brushless commutation to control torque, speed, and direction.









