


PMB33F-10214-02 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
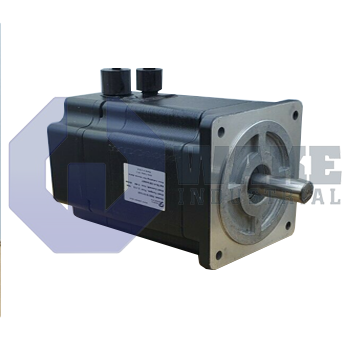
The Pacific Scientific PMB33F-10214-02 is a brushless servomotor from the PMB Brushless Servomotors series. It features a NEMA Size 34 motor, round shaft design, and 11.0 ARMS nominal stall current at 240 VAC. This model has a 2048 ppr digital encoder with commutation and is equipped with flying leads with MS connectors and a PTC thermistor.
Internal Product Review
The PMB33F-10214-02 is a PMB Series brushless servomotor built in a NEMA Size 34 frame for precise servo integration. Digital encoder commutation and 2048 ppr feedback support clean positioning response and dependable control tuning. Flying leads with MS connectors and an integrated PTC thermistor add practical installation value, making the servomotor a strong choice for reliable servo performance.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-10214-02 is a brushless servomotor built by Pacific Scientific and supplied within the PMB Brushless Servomotors series. As a permanent-magnet, low-maintenance actuator, the unit converts drive current from a matching amplifier into precisely regulated torque and velocity for positioning tables, indexing equipment, or pick-and-place modules. The motor integrates an internal digital feedback device so motion controllers can close tight servo loops, making it suitable for mid-power axes that demand repeatable accuracy in industrial automation cells.
With a frame designation of NEMA Size 34, the motor fits standard 3.4-inch square mounting patterns, simplifying interchange with legacy stepper or servo frames. At locked rotor, it can draw up to 11.0 ARMS from a 240 V AC bus. This stall current affects amplifier sizing and thermal limits when the shaft is held. The integrated feedback device delivers 2048 ppr incremental resolution, enabling controllers to command sub-arcminute moves without external gear reduction. Power and signal wiring exit as flying leads with MS connectors, allowing quick disconnection while preserving environmental sealing. Rotor position for commutation is derived from a digital encoder with commutation, eliminating separate Hall sensors and reducing cable count.
Thermal safeguarding is handled by a PTC thermistor embedded in the winding; this device changes resistance sharply as the copper approaches rated temperature so the drive can initiate a controlled shutdown. The output end uses a round shaft, easing coupling to timing pulleys or flexible couplings without keyways. Electromagnetic capacity is associated with a stack height code of 3, which gives a moderate torque plateau and balances inertia against acceleration demands. The motor is suitable for continuous duty in multi-axis assemblies.









