


PMB33F-10214-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
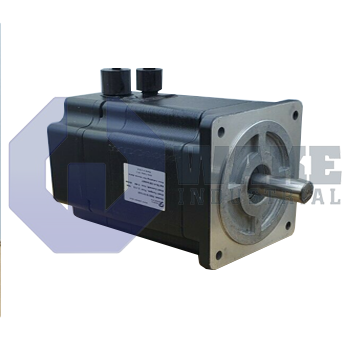
The Pacific Scientific PMB33F-10214-00 is a NEMA Size 34 brushless servomotor and part of the PMB Brushless Servomotors series. This standard motor features flying leads with MS connectors, a round shaft design, and uses a digital encoder with commutation offering 2048 pulse per revolution resolution. It has a nominal stall current of 11.0 ARMS at 240 VAC max and uses a stack length multiple of 3.
Internal Product Review
The PMB33F-10214-00 is a Pacific Scientific PMB Series brushless servomotor built in a NEMA Size 34 frame. A digital encoder with commutation and 2048 ppr resolution supports clean feedback and dependable servo tuning. Flying leads with MS connectors simplify integration, making the standard motor a strong choice for precise motion applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-10214-00 is a brushless servomotor manufactured by Pacific Scientific and delivered in the PMB Brushless Servomotors series. In automated equipment, it converts amplifier commands into controlled torque and speed so that linear tables, rotary indexers, and compact robotic axes can follow programmed motion with repeatable accuracy. Its permanently excited electromagnetic design eliminates brush wear, which helps reduce routine maintenance and supports continuous-duty positioning. This operating style also gives the motor the fast response expected in closed-loop servo systems where steady tracking and smooth correction are required.
Its frame follows the NEMA size 34 standard, so the face pattern matches common mounts and gearheads used on compact motion axes. Feedback is supplied by an optical encoder rated at 2048 ppr, which provides a pulse stream suitable for precise speed and position feedback. The sensing package is a digital encoder with commutation, so the drive receives both incremental feedback and the commutation signals needed for proper electronic switching. When operated from a 240 VAC bus, the winding has a nominal stall current of 11.0 ARMS, which helps determine suitable drive sizing and thermal loading. Electrical connections are routed through flying leads with MS connectors, allowing power, signal, and ground conductors to be terminated without a separate motor terminal box.
The mechanical output uses a round shaft, so clamping hubs and set-screw couplings can be positioned along the machined surface without aligning to a key. Extra torque capability comes from a stack length multiple of 3, which increases the active magnetic length while keeping the same frame outline. It is supplied as a standard motor, using the regular winding and magnet arrangement for this model rather than a special build. That combination makes the motor suitable for general-purpose servo axes where stable feedback, compact mounting, and consistent coupling geometry are needed.









