


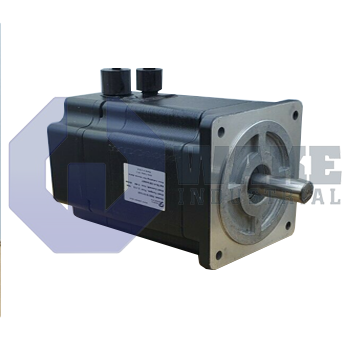
PMB33F-10114-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
6 Minutes
47 Seconds
The Pacific Scientific PMB33F-10114-01 is a brushless servomotor from the PMB Brushless Servomotors series with a NEMA Size 34 housing and round shaft design. It features a digital encoder with commutation at 2048 ppr resolution and a nominal stall current of 11.0 ARMS at 240VAC maximum. The motor comes with flying leads and AMP connectors and includes a shaft seal customization.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-10114-01 is a brushless servomotor produced by Pacific Scientific for the PMB Brushless Servomotors series. This low-inertia motor is intended for positioning and speed-regulated axes in automated machinery where rapid response and repeatable motion are required. Within an integrated drive system, it converts electrical power into tightly controlled rotary motion that can be synchronized with PLC-based command sequences. Its brushless design supports smooth torque production and predictable response during repeated acceleration and deceleration cycles.
The frame is classified as NEMA Size 34, so its mounting holes and pilot diameter match standardized 3.4-inch face dimensions often used on medium-torque tables or conveyors. During worst-case stall at 240 VAC, the windings can carry a nominal current of 11.0 ARMS, so the connected drive must support that level without exceeding thermal limits. Rotor position feedback comes from a 2048 ppr incremental code disk, giving the controller fine position information for precise commutation and servo loop closure. Power and signal conductors exit the housing as flying leads with AMP connectors, which allows flexible harness routing while retaining keyed plug-in mating. The sensing element is a digital encoder with commutation, eliminating the need for separate Hall sensors and reducing wiring complexity.
The mechanical interface uses a round shaft, which simplifies coupler selection when backlash-free clamping hubs or timing pulleys are required. An available shaft seal helps keep lubricants in and airborne particles out of the front bearing cavity. The shaft form also works well with direct-coupled motion components that do not use a keyed connection. To reach higher continuous torque without enlarging the frame, the motor uses a stack length multiple 3 lamination set that extends the active magnetic path while keeping inertia proportional. The longer magnetic stack increases torque capability while preserving the mounting size used by the motor.









