


PMB33F-10114-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
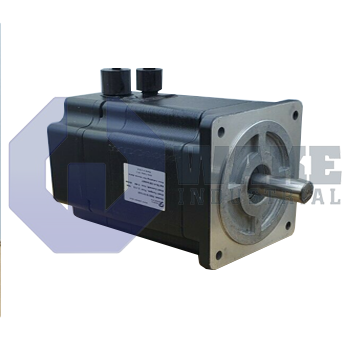
The Pacific Scientific PMB33F-10114-00 is a brushless servomotor in the PMB Brushless Servomotors series, featuring a NEMA Size 34 motor and a round shaft design. This standard motor uses a digital encoder with commutation, providing 2048 pulses per revolution. It has flying leads with AMP connectors and a nominal stall current of 11.0 ARMS at 240 Vac max.
Internal Product Review
The PMB33F-10114-00 is a Pacific Scientific PMB Series brushless servomotor in a NEMA Size 34 frame, well suited for precise motion applications. A 2048 ppr digital encoder with commutation provides accurate feedback and smooth control response. Flying leads with AMP connectors and a standard motor configuration support straightforward integration and dependable serviceability.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-10114-00 is a brushless servomotor produced by Pacific Scientific within the PMB Brushless Servomotors series. Intended for closed-loop speed and position regulation, it serves as the prime mover on indexing tables, pick-and-place heads, and other automated axes in manufacturing cells. Electrical commutation eliminates brushes, and integrated electronic feedback maintains angular accuracy over long duty cycles. When paired with an appropriate drive, the motor converts commanded current into proportional torque, supporting precise, repeatable motion in industrial machinery. The feedback arrangement also helps the control system correct position errors during repeated starts, stops, and directional changes.
During locked-rotor operation, the motor can withstand a continuous phase current of 11.0 ARMS, indicating how much thermal load the windings can endure when maximum holding torque is demanded. That current rating is specified at a bus limit of 240 Vac, so the connected drive must provide suitable headroom at that supply level. Mechanical integration follows the NEMA Size 34 footprint, allowing the housing to fit standard 3.4-inch square mounts without adapters. Field wiring is simplified by flying leads with AMP connectors, which remove the need for a separate terminal strip and support straightforward cable routing. Rotor alignment data are supplied by an onboard digital encoder with commutation, permitting the drive to establish phase relationship quickly at startup.
Motion resolution is refined by an optical code wheel that offers 2048 ppr, allowing the drive to detect small position changes during indexing and speed control. The unit is delivered as a standard motor, so its magnetic, thermal, and mechanical characteristics follow the normal production configuration. A round shaft simplifies coupling to pulleys or flexible hubs without additional machining. Internally, the stator uses stack length 3, balancing copper fill against rotor inertia for moderate acceleration profiles. This combination supports stable servo response when the load changes through normal production cycles.









