


PMB33F-10100-03 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
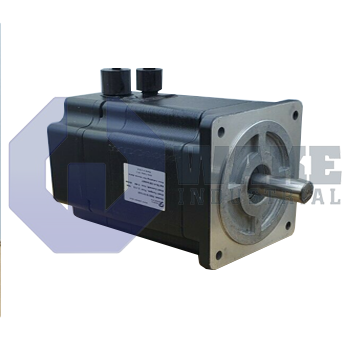
The Pacific Scientific PMB33F-10100-03 is a NEMA Size 34 brushless servomotor from the PMB Brushless Servomotors series. It features flying leads with AMP connectors and a round shaft design. The servomotor comes equipped with a resolver sensor type and includes a shaft seal with PTC thermistor.
Internal Product Review
The PMB33F-10100-03 is a Pacific Scientific PMB Series brushless servomotor with resolver feedback for stable, accurate positioning. Flying leads with AMP connectors simplify panel wiring, while the shaft seal and PTC thermistor option add useful protection for demanding duty cycles. An 11.0 ARMS nominal stall current supports solid low-speed torque performance, making this servomotor a dependable choice for servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-10100-03 is a brushless servomotor engineered by Pacific Scientific and supplied in the PMB Brushless Servomotors series. It serves as a rotary actuator for coordinated position and velocity loops in industrial automation, allowing machine axes to follow drive commands with repeatable accuracy during indexing, transfer, and synchronized motion. As a member of the PMB product line, the unit pairs with low-inductance drives that energize its three-phase windings to generate controlled torque. The absence of brushes lowers maintenance and supports continuous duty in conveyors, pick-and-place stages, packaging equipment, and other automated handling systems.
The motor occupies the NEMA Size 34 frame, giving it standardized face dimensions for integration into existing assemblies. Power, signal, and ground exit through flying leads with AMP connectors, so installation can proceed without a mating terminal box. When locked at stall under a 240 VAC bus, the windings draw a nominal current of 11.0 ARMS, and this value is used to size the drive inverter’s continuous output and cabling ampacity. Rotor position is resolved by a resolver, which supplies two sinusoidal channels to the control system and tolerates high ambient temperatures and electrical noise better than optical encoders. A round output shaft simplifies coupling alignment and avoids the stress concentrations associated with keyed interfaces, suiting duties that rely on compression fittings or collets.
Factory configuration adds a shaft seal and PTC thermistor, giving the servomotor basic ingress protection and embedded overtemperature sensing for controlled shutdown. The magnetic core uses a Stack Length Multiple of 3, which indicates a third lamination segment. This longer stack increases continuous torque while keeping the external dimensions unchanged. The motor uses electrical constants and mounting codes common to the platform, so it follows the standard drive and mounting conventions used across the product line.









