


PMB33F-00216-03 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
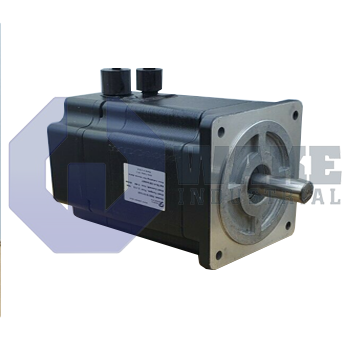
The Pacific Scientific PMB33F-00216-03 is a brushless servomotor from the PMB Brushless Servomotors series and is built in a NEMA Size 34 housing with a flat shaft design. It features a digital encoder with commutation and a resolution of 4096 pulses per revolution, along with a nominal stall current of 11.0 ARMS at 240Vac max. The servomotor is equipped with flying leads and MS connectors, and includes both a shaft seal and PTC thermistor for additional protection and customization.
Internal Product Review
The PMB33F-00216-03 is a Pacific Scientific PMB Series brushless servomotor with a NEMA Size 34 frame. Digital encoder feedback at 4096 ppr supports precise positioning, while flying leads with MS connectors simplify integration. A shaft seal and PTC thermistor add practical protection features, making the motor a strong choice for demanding servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-00216-03 is a brushless servomotor manufactured by Pacific Scientific as part of the PMB Brushless Servomotors series. It supplies closed-loop rotational power in industrial automation systems, providing responsive torque and speed regulation for indexing, conveying, and general motion axes. Because it uses brushless construction, the motor supports smooth electronic commutation and avoids the brush wear associated with older motor designs. In a typical servo system, the motor works with a compatible drive that compares command signals with feedback and corrects speed or position errors in real time.
The motor’s physical envelope follows the NEMA Size 34 frame, which fits the common 3.4-inch face format used in many motion packages. Electrical feedback is supplied by a 4096 ppr incremental encoder, so the drive receives high-resolution position data for accurate control. Commutation data comes from a digital encoder with commutation, which removes the need for separate Hall sensors and reduces the number of feedback devices in the system. Power and feedback leave the housing through flying leads with MS connectors, allowing connection to matching MIL-style plugs. This arrangement keeps the power and feedback interfaces on the motor body rather than requiring a separate terminal box. At 240 VAC, the winding can sustain a nominal stall current of 11.0 ARMS, which indicates the continuous current the motor can carry at standstill without overheating.
The output end uses a flat shaft, which provides a simple way to couple set-screw hubs while maintaining concentric rotation. A shaft seal protects the front bearing area from oil mist and dust, and an embedded PTC thermistor provides temperature feedback so the drive can reduce output or shut down before the winding gets too hot. Magnetic capability is increased by a stack length multiple of 3, meaning three lamination sections are used to raise torque relative to shorter motors in the same frame. This longer active stack increases torque capacity without changing the motor’s mounting footprint.









