


PMB33F-00216-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
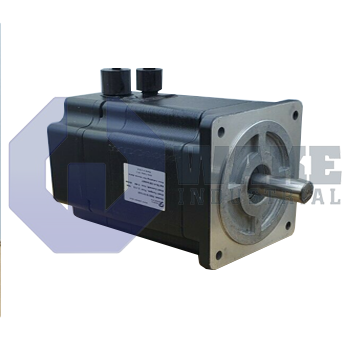
The Pacific Scientific PMB33F-00216-01 is a NEMA Size 34 brushless servomotor from the PMB Brushless Servomotors series with a flat shaft design and customization for a shaft seal. It features an encoder with a resolution of 4096 ppr and uses flying leads with MS connectors. The servomotor has a nominal stall current of 11.0 ARMS at 240Vac maximum and includes a digital encoder with commutation.
Internal Product Review
The PMB33F-00216-01 is a Pacific Scientific PMB Series brushless servomotor in a NEMA Size 34 frame with flying leads and MS connectors. A digital encoder with commutation and 4096 ppr feedback supports accurate positioning, making the unit an excellent choice for precise motion applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-00216-01 is a brushless servomotor built by Pacific Scientific within the PMB Brushless Servomotors series. Designed for closed-loop motion modules, it converts electrical power into precise rotary movement, allowing automated equipment to position loads quickly and repeatably in industrial assembly cells. Its permanent-magnet rotor and electronic feedback allow the drive to maintain accurate velocity and torque control during acceleration, deceleration, and holding. This operating profile suits pick-and-place gantries, compact indexers, and small packaging axes that require stable motion through repeated cycles.
The motor frame conforms to the NEMA Size 34 outline, so mounting holes and shaft height align with common gearheads and slide adapters. Position feedback is delivered by a 4096 ppr incremental signal, and the digital encoder with commutation provides phase information so the drive applies current at the correct electrical angle. A nominal stall current of 11.0 ARMS at 240 VAC indicates the continuous phase current the amplifier must supply when the rotor is locked under rated load. Power and signal conductors exit as flying leads with MS connectors, which helps cable routing in compact machine spaces and supports separation of motor and feedback wiring.
The output shaft has a flat, so clamp-style couplings can transmit torque without a keyed connection. To protect the front bearing area from coolant or dust, the motor is supplied with a shaft seal, which helps limit contaminant entry in washdown or abrasive environments. The electromagnetic section uses a stack length of 3, increasing copper volume and supporting higher continuous torque than shorter versions of the same frame. That longer active section also helps the motor handle repeated starts and stops on compact axes where steady thermal performance is important.









