


PMB33F-00214-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
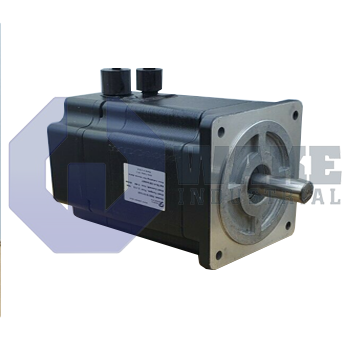
The Pacific Scientific PMB33F-00214-00 is a brushless servomotor from the PMB Brushless Servomotors series, featuring a NEMA Size 34 frame and flat shaft design. It is equipped with a digital encoder with commutation, offering a resolution of 2048 pulses per revolution and flying leads with MS connectors. The motor supports a nominal stall current of 11.0 ARMS at 240VAC max and has a stack length multiple of 3.
Internal Product Review
The PMB33F-00214-00 is a PMB Series brushless servomotor in a NEMA Size 34 format, well suited for precise motion control. Flying leads with MS connectors simplify integration, and the 2048 ppr encoder supports accurate feedback. The 11.0 ARMS nominal stall current is a strong technical advantage for demanding servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-00214-00 belongs to the PMB Brushless Servomotors series produced by Pacific Scientific. It is a three-phase permanent-magnet unit intended to generate controlled torque in automation cells, motion stages, and material-handling axes. When paired with a digital servo drive and encoder feedback, the motor supports closed-loop positioning for applications that need repeatable starts, stops, and speed changes. Its permanent-magnet design also supports efficient servo response during continuous-duty operation.
Mechanical fit is set by the NEMA Size 34 frame, so mounting uses a 3.4-inch square pilot common to many drive packages. Thermal loading is limited by a nominal stall current of 11.0 ARMS when the windings are energized from a 240 VAC bus, so the amplifier must supply that current continuously without exceeding motor insulation limits. Field wiring exits through flying leads with MS connectors, providing strain-relieved cabling that mates quickly to panel receptacles and supports straightforward routing inside the machine. Position feedback comes from a rotor-mounted digital encoder with commutation that provides an incremental output of 2048 ppr, giving the drive 12-bit angular resolution for phase advance, velocity regulation, and stable low-speed control.
A flat shaft terminates the rotor, allowing clamp-style couplings to grip the output without adding keyseats and helping preserve concentricity at the coupling. The electromagnetic core uses a stack length multiple of 3, which increases usable torque while keeping inertia appropriate for mid-mass loads that must reverse direction rapidly. The unit is supplied as a standard motor, so it uses the standard configuration for this model rather than a custom build. This arrangement supports general servo installations that use standard electrical and feedback features.









