


PMB33F-00116-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
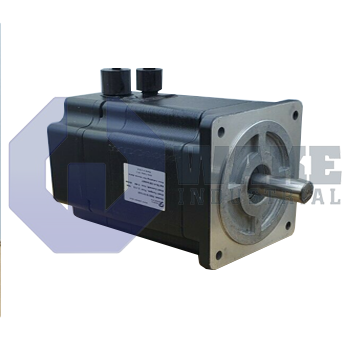
The Pacific Scientific PMB33F-00116-01 is a NEMA Size 34 brushless servomotor from the PMB Brushless Servomotors series. It features a flat shaft design with shaft seal customization and uses flying leads with AMP connectors. The motor has a nominal stall current of 11.0 ARMS at 240VAC and includes a digital encoder with commutation and a 4096 ppr resolution.
Internal Product Review
The PMB33F-00116-01 is a Pacific Scientific PMB Series brushless servomotor in a NEMA Size 34 frame. A digital encoder with commutation and 4096 ppr resolution supports precise feedback and dependable servo tuning. Flying leads with AMP connectors simplify integration, and the shaft seal adds welcome durability for motion systems.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-00116-01 is a brushless servomotor produced by Pacific Scientific as part of the PMB Brushless Servomotors series. Designed for motion axes that need accurate speed and torque regulation, the motor converts electrical energy from a matched drive into controlled rotary force so actuators, indexing tables, or gantries can follow precise profiles in automated equipment. Its electromagnetic design and integral feedback place it in the mid-frame class for packaging systems, pick-and-place units, and light machine-tool stations. This arrangement allows the drive to correct position and velocity error during acceleration, deceleration, and load changes.
Electrical interfacing is provided through flying leads with AMP connectors, allowing direct connection in control cabinets without an intermediate terminal block. At the rotor, a 4096 ppr incremental encoder supplies high-resolution feedback, and the feedback device is a digital encoder with commutation, so the drive receives both position data and phase-alignment information. The motor follows the NEMA Size 34 outline, allowing it to fit standard mounting patterns used with common couplings and gearheads. Under locked-rotor test conditions, the winding draws 11.0 ARMS from a 240 VAC drive, which indicates the current demand present when the shaft is not turning.
The motor uses a flat output shaft, which simplifies pulley or clamp-style hub attachment. A customer-specified shaft seal helps limit lubricant migration toward the feedback cavity and reduces the chance of contamination near the encoder components. Torque density benefits from the 3 lamination multiple, which adds magnetic material without enlarging the frame. In this model family, the lamination buildup is referred to as the stack length, a term commonly used when distinguishing torque capability between similar frame sizes.









