


PMB33F-00101-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
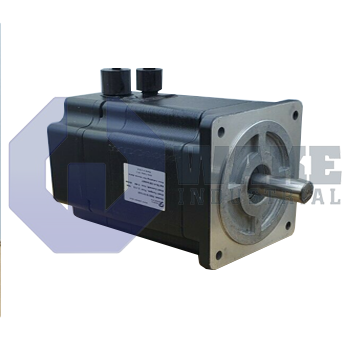
The Pacific Scientific PMB33F-00101-00 is a standard motor from the PMB Brushless Servomotors series with a NEMA Size 34 frame and a stack length multiple of 3. It features flying leads with AMP connectors and a flat shaft design. The servomotor includes a Hall sensor and has a nominal stall current of 11.0 ARMS at 240 Vac maximum.
Internal Product Review
The PMB33F-00101-00 is a PMB Series brushless servomotor from Pacific Scientific in a NEMA Size 34 frame for precise motion control duties. Hall sensor feedback and flying leads with AMP connectors support dependable commutation and straightforward installation. The standard motor configuration and 11.0 ARMS nominal stall current make this servomotor a strong choice for consistent servo performance.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33F-00101-00 is a brushless servomotor engineered by Pacific Scientific within the PMB Brushless Servomotors series. This rotary actuator converts the regulated output of a servo drive into precise torque and speed for pick-and-place stations, indexing tables, and coordinated mechanical axes throughout automated equipment. The brushless architecture eliminates commutator wear, which reduces maintenance and helps the motor hold commanded velocities during extended production cycles. When integrated with closed-loop control electronics, it supplies consistent motion that keeps manufacturing cells synchronized to programmed trajectories.
Mechanical dimensions follow the NEMA Size 34 pattern, so the mounting face aligns with industry-standard accessories. On the electrical side, the motor’s windings support an 11.0 ARMS nominal stall current when operated from a 240 Vac bus, establishing the continuous torque boundary before thermal derating is required. This current figure also affects conductor gauge, fuse sizing, and heat sink area inside the drive enclosure. Rotor position is detected by an internal Hall sensor, which switches at 60 electrical degrees to feed commutation signals to the inverter at low speed where resolver or encoder feedback is not necessary. Field wiring exits the stator as flying leads with AMP connectors, permitting direct crimp termination into cabinet harnesses and shortening installation time by eliminating a junction box.
The load interface uses a flat shaft so set-screw couplings can transfer torque without keys, reducing machining complexity and stress concentrations on the hub. A stack length multiple of 3 enlarges the active magnetic path and increases continuous torque without altering the external frame size. The motor is cataloged as a Standard Motor. This arrangement keeps the motor suitable for common machine layouts while preserving a compact overall envelope.









