


PMB33E-10116-03 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
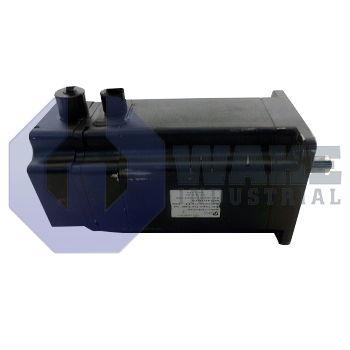
The Pacific Scientific PMB33E-10116-03 is a brushless servomotor from the PMB Brushless Servomotors series. It features a NEMA Size 34 frame and a digital encoder with commutation offering 4096 pulses per revolution. The motor has a round shaft design, flying leads with AMP connectors, and includes both a shaft seal and a PTC thermistor for customization.
Internal Product Review
The PMB33E-10116-03 is a Pacific Scientific PMB Series brushless servomotor with a NEMA Size 34 frame. A digital encoder with commutation and 4096 ppr resolution support precise feedback and stable motion control tuning. Flying leads with AMP connectors simplify integration, while the shaft seal and PTC thermistor add valuable protection for demanding servo applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33E-10116-03 belongs to the PMB Brushless Servomotors series engineered by Pacific Scientific. It is a permanent-magnet AC unit intended to supply repeatable torque and smooth speed control for positioning axes, indexing tables, and similar industrial automation tasks. Built around the established PMB electromagnetic platform, the motor integrates feedback and power conductors so it can be paired with matched digital drives and motion controllers on factory machinery. This arrangement supports closed-loop motion where stable current delivery and accurate position response are needed during frequent starts, stops, and speed changes.
The frame conforms to NEMA size 34, so the mounting face and pilot diameter align with standard U.S. 3.4-inch flange patterns frequently found on medium-duty actuators. A nominal stall rating of 7.4 ARMS at 240 VAC indicates the continuous phase current the winding can tolerate without exceeding thermal limits, which helps match the motor to a suitable drive. Power exits the housing through flying leads with AMP connectors, eliminating separate junction boxes and allowing direct cable harnessing on moving carriages. Rotor position is reported by an optical encoder that delivers 4096 ppr, giving the control loop 12-bit positional granularity for low-velocity creep and high-speed interpolation with consistent feedback resolution.
Feedback integrity is maintained by a digital encoder with commutation channel, so initial electrical alignment is performed automatically at power-up instead of by manual phasing. The shaft is round, enabling couplings or toothed pulleys to be press-fit without keyways and making it suitable for clamp-style drive elements. Environmental protection is enhanced through a shaft seal and PTC thermistor; the seal blocks oil or dust at the nose while the thermistor lets the drive react to rising winding temperature during extended operation. The laminated core uses a stack length multiple of 3, which adds iron depth for higher torque density without changing the front-face geometry.









