


PMB33E-10116-02 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
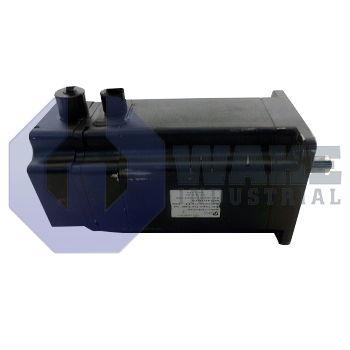
The Pacific Scientific PMB33E-10116-02 is a brushless servomotor from the PMB Brushless Servomotors series. This NEMA Size 34 motor features a sensor type of digital encoder with commutation and an encoder resolution of 4096 pulses per revolution. It has flying leads with AMP connectors and a nominal stall current of 7.4 ARMS at 240VAC.
Internal Product Review
The PMB33E-10116-02 is a PMB Series brushless servomotor with a NEMA Size 34 frame. A digital encoder with commutation and 4096 ppr feedback support accurate positioning and stable servo response, making this unit a strong choice for precise motion control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33E-10116-02 is a brushless servomotor built by Pacific Scientific as part of the PMB Brushless Servomotors series. It is intended for closed-loop positioning and speed regulation in automated conveyors, pick-and-place axes, and other mid-torque motion systems where repeatability and compact mounting are required. Within these systems, the motor converts drive current into precise rotary motion while its internal feedback device reports actual shaft position to the controller. It can also be used on indexing tables, transfer mechanisms, and similar automation axes that need consistent motion in a compact package.
This model is supplied with flying leads with AMP connectors, so cabling can be routed directly to compatible drive plugs or terminal connections without extra adapters. The frame is rated as NEMA Size 34, which provides a 3.4-inch square mounting face that matches common gearboxes and indexers. At 240 VAC, the winding reaches a nominal stall current of 7.4 ARMS. A high-resolution feedback element delivers 4096 ppr of incremental data for fine commutation and smooth low-speed control. That feedback comes from a digital encoder with commutation, which removes the need for separate Hall sensors, and the stack length multiple of 3 adds active iron for higher torque density. The mounting format also helps the motor fit standard machine hardware without special faceplate changes.
Thermal protection is integrated through a PTC thermistor embedded in the windings, so the drive can respond if temperature rises past the preset threshold. Because the sensor is inside the motor, temperature changes can be detected close to the windings rather than only at the outer housing. The motor also uses a round shaft, which allows direct coupling with clamp or set-screw hubs when low backlash is important. Its mechanical layout suits compact servo installations, and the winding and feedback package support steady operation across positioning and speed-control duties.









