


PMB33E-10114-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
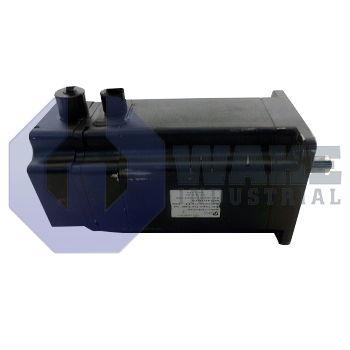
The Pacific Scientific PMB33E-10114-01 is a brushless servomotor from the PMB Brushless Servomotors series with a NEMA Size 34 frame and round shaft design. It features a 2048 ppr digital encoder with commutation, flying leads with AMP connectors, and a nominal stall current of 7.4 ARMS at 240 VAC.
Internal Product Review
The PMB33E-10114-01 is a Pacific Scientific PMB Series brushless servomotor with a digital encoder and commutation for accurate feedback control. A NEMA Size 34 frame and 7.4 ARMS nominal stall current support confident servo integration and stable torque delivery. Flying leads with AMP connectors and a shaft seal make this motor a well-executed choice for dependable industrial motion service.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33E-10114-01 is a brushless servomotor built by Pacific Scientific within the PMB Brushless Servomotors series. It is intended for servo axes in automated packaging lines, indexing tables, and material transfer modules where accurate positioning and rapid reversals are required. The motor produces continuous rotary torque, while encoder feedback allows integration with digital amplifiers for closed-loop motion control. Its permanent-magnet rotor eliminates brush wear, supporting long service life in duty-cycle-intensive environments. This arrangement suits axes that must start, stop, and reverse frequently without the brush dust or commutator wear associated with older motor styles.
The frame conforms to NEMA Size 34, which gives a 3.4-inch square mounting face compatible with many standard gearheads and brackets. A lamination stack multiplier of 3 extends the magnetic path length, increasing continuous torque without changing the footprint. During startup or stall, the winding can accept 7.4 ARMS from a 240 VAC drive, so cabling and drive sizing must match this current. Electrical termination is delivered as flying leads with AMP connectors, enabling direct crimp-style mating inside a control enclosure and eliminating a separate junction box. Feedback resolution is 2048 ppr, allowing the controller to resolve 0.18° mechanical increments, which improves velocity and position control in mid-speed applications.
A customized shaft seal is fitted to limit lubricant egress and to protect the front bearing against airborne contaminants. Rotor output is through a round shaft, simplifying coupler alignment when the load side already uses a keyed hub or clamp collar. Commutation and position data are supplied by a digital encoder with commutation, so separate Hall sensors are unnecessary and the feedback device supports both rotor position tracking and electronic commutation. The motor follows the family part-numbering and thermal conventions used across the series for compatible electrical behavior.









