


PMB33E-00214-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
6 Minutes
15 Seconds
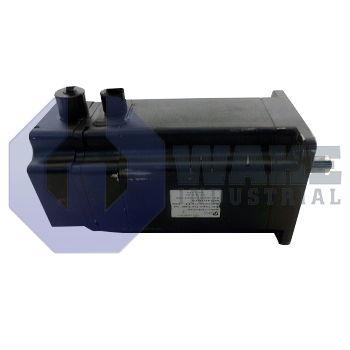
The PMB33E-00214-00 is a brushless servomotor produced by Pacific Scientific as part of the PMB Brushless Servomotors series. It features a NEMA Size 34 motor with a flat shaft design and includes a digital encoder with commutation at 2048 pulses per revolution. The servomotor uses flying leads with MS connectors and has a nominal stall current of 7.4 ARMS at 240 VAC.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33E-00214-00 belongs to the PMB Brushless Servomotors series manufactured by Pacific Scientific. It is a brushless servomotor intended for positioning and speed-controlled axes in industrial automation where compact size, closed-loop feedback, and repeatable torque are required. Because it uses brushless servo operation, it can support repeatable motion in systems that demand stable speed and position control. Its compact format suits machines where servo performance must fit limited installation space.
This motor is built on a NEMA Size 34 frame, so it mates directly with gearheads and mounts that follow the NEMA dimensional standard. When operated from a 240 VAC supply, its nominal stall current reaches 7.4 ARMS, so the connected drive and motor leads must support that continuous phase demand. Rotor position is captured by a digital encoder that outputs 2048 ppr, giving the controller high-resolution feedback for speed regulation and commutation. High encoder resolution also helps the controller maintain smooth low-speed operation and reliable phase alignment during acceleration. Power and feedback exit the housing through flying leads with MS connectors, which keeps the electrical interface compact at the motor body. The feedback device is an integrated digital encoder with commutation, so separate Hall sensors are not required.
This unit is supplied as a Standard Motor, so its winding and mechanical options follow the standard configuration for this model. The rotor uses a flat shaft, which allows setscrew couplings to lock onto the shaft without keys. Internally, the stator uses a stack length multiple of 3, adding iron length to support higher continuous torque within the same footprint. That layout increases active material without changing the basic frame size. Common uses include indexing tables, compact robots, and automated test equipment that need steady servo control and straightforward electrical connections.









