


PMB33E-00116-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
4 Minutes
45 Seconds
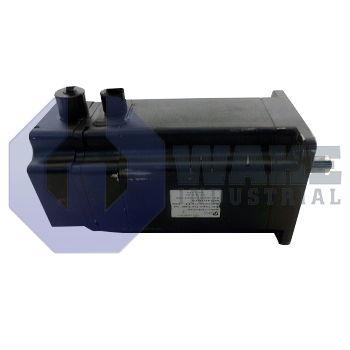
The Pacific Scientific PMB33E-00116-01 is a brushless servomotor from the PMB Brushless Servomotors series, featuring a NEMA Size 34 frame and a flat shaft design. It has a nominal stall current of 7.4 ARMS at 240 VAC max and uses a digital encoder with a resolution of 4096 pulses per revolution. This motor comes with flying leads and AMP connectors as well as a shaft seal customization.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33E-00116-01 is a brushless servomotor built by Pacific Scientific as part of the PMB Brushless Servomotors series. This unit converts drive current into controlled rotary motion for positioning axes, index tables, and other precision tasks in automated machinery. It integrates with servo amplifiers from the same vendor family and supplies feedback through an onboard encoder so the drive can close a high-resolution speed and position loop. Its compact form supports motion systems that require repeatable response and steady low-speed control.
The motor body uses the NEMA size 34 frame, which provides a standardized 3.4-inch square mounting face that matches common gearheads and brackets. The motor has a nominal stall current of 7.4 ARMS when the drive is supplied from 240 VAC, and this value is relevant to conductor, fuse, and thermal protection selection. Rotor position data is produced in 4096 ppr increments, giving the controller fine feedback resolution for precise speed and position control. Power and feedback conductors exit as flying leads with AMP connectors, so the motor can be connected without a separate molded plug body at the housing. Mechanical power density is increased by a 3-stack lamination core, which raises magnetic active length while keeping the outer frame compact.
The commutating sensor is a digital encoder with commutation, and its additional UVW tracks let the drive energize the phases in the correct sequence immediately after startup. A factory-fitted shaft seal blocks lubricant migration and helps keep particulates away from the bearings during operation in dusty environments. The output end uses a flat shaft, a simple geometry that mates directly with set-screw couplings and avoids the stress concentration associated with a keyed slot. This arrangement supports smooth torque production during low-speed indexing and stable signal handling across the full speed range.









