


PMB33E-00114-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
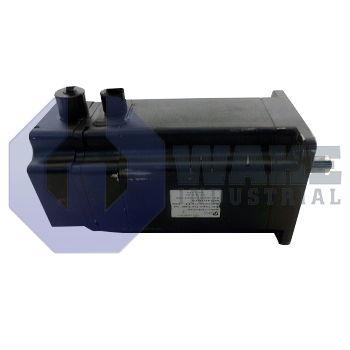
The Pacific Scientific PMB33E-00114-00 is a standard motor in the PMB Brushless Servomotors series, featuring a NEMA Size 34 frame and a flat shaft design. It has a digital encoder with commutation and an encoder resolution of 2048 pulses per revolution. The servomotor is equipped with flying leads using AMP connectors and operates with a nominal stall current of 7.4 ARMS at 240 VAC max.
Internal Product Review
The PMB33E-00114-00 is a PMB Series brushless servomotor built in a NEMA Size 34 frame for capable servo-axis duty. A digital encoder with commutation and 2048 ppr feedback support clean signal resolution and dependable positioning performance. Flying leads with AMP connectors simplify integration, making the motor a strong choice for precise motion systems.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33E-00114-00 is a brushless servomotor produced by Pacific Scientific within the PMB Brushless Servomotors series. Intended for precision motion loops in industrial automation, this unit converts drive current into tightly regulated rotary movement for positioning tables, small gantries, and material-handling axes. It works with mid-power servo amplifiers and supports stable velocity control during continuous-duty operation, which makes it suitable for repeatable indexing and positioning tasks on compact automated equipment.
The motor is supplied with flying leads with AMP connectors, so cabling can be routed directly to a terminal block or drive without a mating receptacle on the housing. Built as a standard motor, it follows the base mechanical options used in the series. Feedback resolution is 2048 ppr, allowing the control system to command fine shaft increments. Its mounting envelope follows NEMA Size 34 conventions, so the face, bolt circle, and pilot diameter match other devices in that frame. At 240 VAC, the winding can withstand a nominal stall current of 7.4 ARMS, which supports continuous torque within the motor's thermal limits. The unit is a PMB Series Brushless Servomotor, which uses permanent-magnet excitation and sinusoidal commutation.
Rotor position is reported by a digital encoder with commutation tracks, so separate Hall sensors are not required. A flat shaft end provides a simple driving surface for set-screw couplings. The laminations use a stack length multiple of 3, increasing active iron for higher torque without changing the frame size. The flying-lead arrangement allows direct routing to the drive or terminal block, and the shaft form helps maintain secure coupling during rapid accelerations. Encoder feedback also supports fine positional interpolation and smooth low-speed indexing in compact automation axes.









