


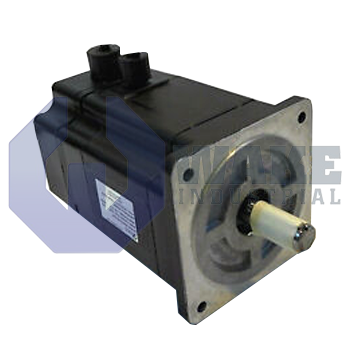
PMB33C-10216-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
4 Minutes
6 Seconds
The PMB33C-10216-00 is a brushless servomotor from Pacific Scientific, part of the PMB Brushless Servomotors series. It features a NEMA Size 34 motor with a round shaft design and uses a digital encoder with commutation at 4096 pulses per revolution. The motor employs flying leads with MS connectors and has a nominal stall current of 3.8 ARMS at 240 VAC.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33C-10216-00 is a brushless servomotor produced by Pacific Scientific as part of the PMB Brushless Servomotors series. Designed for closed-loop motion axes, the motor converts electrical commands from a servo drive into precise rotary position and speed, making it suitable for pick-and-place stations, indexing tables, and similar industrial automation tasks. Its brushless design provides continuous torque without mechanical commutation, allowing maintenance-free operation in electrically noisy or high-duty-cycle environments. The motor is well suited to applications that require repeatable starts, stops, and controlled speed changes throughout frequent operating cycles.
This unit follows the NEMA size 34 frame standard, so its mounting dimensions align with equipment that uses that face size. Feedback is supplied by a digital encoder rated at 4096 ppr, giving the drive fine angular resolution for velocity and commutation control. On a 240 VAC bus, the nominal stall current is 3.8 A RMS, so the paired drive must be able to deliver that level continuously without foldback. Connections leave the housing as flying leads with MS connectors, enabling quick wiring while maintaining environmental sealing. Position and phase information come from a digital encoder with commutation, so separate Hall sensors are not required and cable count is reduced. This feedback arrangement supports accurate rotor alignment and stable velocity regulation during servo operation.
The motor has a round shaft, which simplifies coupler selection because no keyway is needed on the mating element. A plain round output also works well with clamp-style couplings that rely on friction rather than a keyed joint. The laminated stator stack uses a length multiple of 3, providing more active iron than shorter models in the series and supporting higher continuous torque. It is supplied as a standard motor, so no customer-specific winding or hardware changes are included.









