


PMB33C-10101-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
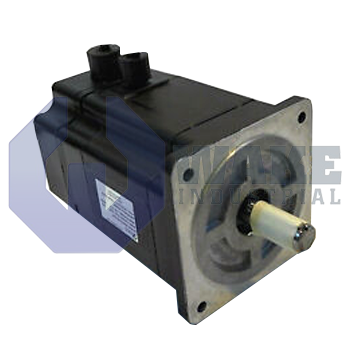
The Pacific Scientific PMB33C-10101-01 is part of the PMB Brushless Servomotors series and features a NEMA Size 34 motor. This servomotor comes with a round shaft design, Hall sensor for position feedback, and flying leads with AMP connectors. It offers a nominal stall current of 3.8 ARMS at 240Vac max and includes a shaft seal customization.
Internal Product Review
The PMB33C-10101-01 is a Pacific Scientific PMB Series brushless servomotor featuring Hall sensor feedback. Flying leads with AMP connectors simplify installation, and the shaft seal configuration adds welcome protection for demanding servo applications. A 3.8 ARMS nominal stall current gives the NEMA Size 34 platform a well-balanced performance profile for precision motion applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33C-10101-01 brushless servomotor is built by Pacific Scientific and belongs to the PMB Brushless Servomotors series. Designed for industrial automation, it supplies continuous rotary torque to actuate feeders, pick-and-place heads, or light gantry axes where rapid acceleration and precise velocity control are required. In a motion system, the motor links directly to a digital drive, allowing electronic commutation and feedback-controlled positioning without the wear associated with brushed machines.
The mechanical interface follows the NEMA Size 34 frame, providing a predictable mounting hole pattern and shaft height for common industrial mounting layouts. Power and feedback exit the housing through flying leads with AMP connectors, so wiring can be connected without separate plug assemblies at the motor body. A factory-installed shaft seal sits behind the front bearing to limit the ingress of lubricant or coolant in washdown areas. The output spindle uses a round shaft, allowing couplers or pulleys to slide on without keyway constraints and reducing stress concentrations. Rotor position information is supplied by an embedded Hall sensor, enabling the drive to establish proper phase alignment during startup and detect coarse speed changes.
The winding has a nominal stall current of 3.8 ARMS, so the drive must be able to source that continuous phase current when the shaft is motionless under rated load. The magnetic circuit uses a stack length code of 3, which increases active iron volume and raises torque compared with shorter cores in the same frame size. As a PMB series brushless servomotor, the model shares electromagnetic characteristics with other motors in the line. The Pacific Scientific motor line uses consistent lead colors, sensor phasing, and mechanical tolerances across related models.









