


PMB33C-00214-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
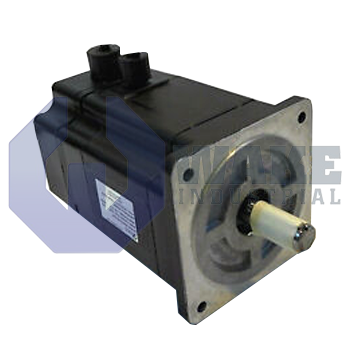
The Pacific Scientific PMB33C-00214-01 is a brushless servomotor that is part of the PMB Brushless Servomotors series. It is a NEMA Size 34 motor with a flat shaft design and a shaft seal customization. The motor uses flying leads with MS connectors and has a digital encoder with commutation, providing 2048 pulses per revolution.
Internal Product Review
The PMB33C-00214-01 is a Pacific Scientific PMB Series brushless servomotor in a NEMA Size 34 frame. A digital encoder with commutation and 2048 ppr feedback support accurate positioning and stable servo response. Flying leads with MS connectors simplify integration, making this servomotor a strong choice for dependable motion control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB33C-00214-01 is a brushless servomotor manufactured by Pacific Scientific and supplied as part of the PMB Brushless Servomotors series. Intended for industrial automation, it converts three-phase drive power into controlled torque and speed so gantry axes, conveyor stations, or indexing tables can maintain position and accelerate as required. This makes it suitable for positioning and speed-controlled duties where repeatable motion is needed during frequent start-stop cycles. The brushless design eliminates commutator wear, and the integrated feedback channels let the motor interface directly with matched digital servo amplifiers.
This model uses a NEMA Size 34 frame, giving it standard face dimensions that support installation in many compact machine layouts. A shaft-mounted encoder provides 2048 ppr resolution, and the drive interprets the pulse train together with commutation tracks for smooth low-speed motion and stable position feedback. Under stall conditions at 240 V AC, the windings draw 3.8 ARMS, and this value is used to set current limits and estimate heat rise during demanding duty cycles. Because the transducer combines incremental channels and Hall signals, the motor uses a digital encoder with commutation for coordinated feedback between the rotor and amplifier. Output torque is delivered through a flat shaft end, which helps prevent coupler slip and maintain angular alignment in belt-driven or gear-driven loads.
Power and signal conductors exit as flying leads with MS connectors, allowing connection without a fixed terminal housing and supporting straightforward cable routing. For applications exposed to spray, mist, or fine particulate, an optional shaft seal protects the front bearing and encoder cavity from contamination. The magnetic core uses a stack length multiple of 3, balancing torque increase against rotor inertia for mid-mass loads that need responsive acceleration. Its electrical constants and timing are compatible with SC and SCE drives, allowing the motor to operate with matched motion platforms that use the same current and voltage range.









