


PMB33C-00116-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
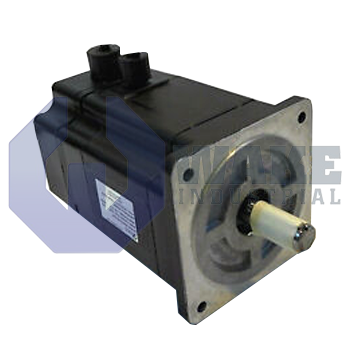
The Pacific Scientific PMB33C-00116-01 is a brushless servomotor from the PMB Brushless Servomotors series with a NEMA Size 34 frame and flat shaft design. It features flying leads with AMP connectors and uses a digital encoder with commutation, offering a 4096 ppr resolution. This motor includes a shaft seal and has a nominal stall current of 3.8 ARMS at 240 VAC.
Internal Product Review
The PMB33C-00116-01 is a Pacific Scientific PMB Series brushless servomotor built in a NEMA Size 34 frame. A digital encoder with commutation and 4096 ppr resolution supports accurate feedback and stable servo tuning. Flying leads with AMP connectors simplify integration, making the servomotor a strong choice for precise motion applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
Pacific Scientific’s PMB33C-00116-01 belongs to the PMB Brushless Servomotors series and is engineered for closed-loop motion tasks in automated assembly, packaging, and material-handling stations. As a permanent-magnet servomotor, it converts drive current into proportional torque so that linear stages and rotary actuators follow commanded profiles with minimal position error. The model is supplied as a compact package that integrates directly with matching servo drives and feedback controllers used across industrial automation cells.
The motor housing conforms to NEMA Size 34 mounting dimensions, allowing installation on machinery plates drilled for that frame. Under a 240 VAC bus, it withstands a nominal stall current of 3.8 ARMS, which the drive must deliver continuously when the load holds position without rotor movement. Power, Hall, and encoder signals exit the stator through flying leads with AMP connectors, enabling quick field wiring without proprietary mating plugs. Rotary sensing resolution reaches 4096 ppr, so each revolution is subdivided into that count for velocity and incremental position calculation. The installed feedback package is a digital encoder with commutation; in addition to incremental tracks, it produces six commutation channels that let the drive energize the correct stator phase pair immediately after power-up.
Contaminant ingress at the output end is limited by a factory-applied shaft seal, helping retain grease in coupled gear stages and reducing downtime in dusty environments. Torque is transferred through a flat shaft, an interface that helps prevent slip when clamped to pulley hubs or couplings without machining keyways. Electromagnetic length uses a stack length multiple of 3, giving greater continuous torque than shorter variants while keeping thermal mass inside typical cabinet cooling limits. The unit is a PMB Series Brushless Servomotor intended for use with compatible servo drives and feedback controllers.









