


PMB32D-00116-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
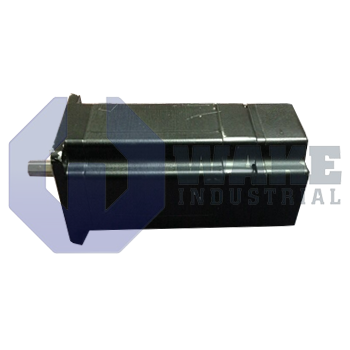
The Pacific Scientific PMB32D-00116-01 is a NEMA Size 34 brushless servomotor from the PMB Brushless Servomotors series. It features a nominal stall current of 5.4 ARMS at 240 Vac and uses flying leads with AMP connectors. This model includes a 4096 ppr digital encoder with commutation and a flat shaft design.
Internal Product Review
The PMB32D-00116-01 is a Pacific Scientific PMB Series brushless servomotor built in a NEMA Size 34 frame with a flat shaft design. The digital encoder with commutation and 4096 ppr resolution support clean feedback and dependable positioning, making this unit a strong choice for precise motion control.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB32D-00116-01 is a brushless servomotor engineered by Pacific Scientific within the PMB Brushless Servomotors series. This rotary unit converts drive current into controlled torque and speed for closed-loop axes in automated machinery, packaging stations, and material handling equipment. By integrating permanent-magnet excitation with electronic commutation, it delivers repeatable positioning and smooth velocity regulation for modern motion control systems. This combination helps the motor maintain stable low-speed behavior and accurate response during repeated indexing, start-stop motion, and steady running. Its construction follows common mounting conventions, so it can be paired directly with compatible digital servo drives.
The motor has a nominal stall current of 5.4 ARMS when powered from a 240 VAC bus. This current marks the continuous torque limit before thermal rise causes derating. The housing uses a NEMA Size 34 footprint, allowing interchange with other 3.4-inch square servomotors on standardized mount patterns. For position feedback, the integrated encoder outputs 4096 ppr, enabling fine command resolution without added interpolation. Commutation and incremental tracks are combined inside a digital encoder with commutation, eliminating separate Hall sensors. All power, signal, and protective earth conductors leave the stator as flying leads with AMP connectors, so cabinet wiring can be completed through simple plug mating rather than field-installed circular connectors.
The motor also includes several application-focused mechanical features. A factory-installed shaft seal blocks lubricant or coolant from reaching the bearing cavity when the motor is mounted in washdown or oil-mist areas. The output shaft is machined with a flat, so torque can be transferred through set-screw couplings without relying on keys. To raise peak torque while holding face dimensions, the stator uses a stack length multiple of 2. These features support use in compact drive systems where space, sealing, and simple shaft coupling all matter.









