


PMB32D-00116-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
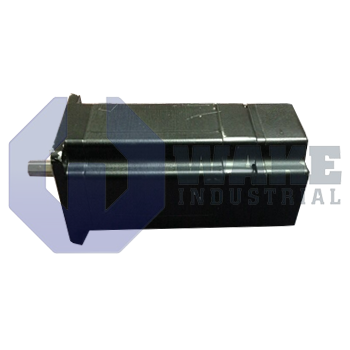
The Pacific Scientific PMB32D-00116-00 is a standard brushless servomotor from the PMB Brushless Servomotors series. It is constructed in NEMA Size 34 with flying leads and AMP connectors, and features a flat shaft design. The motor includes a digital encoder with commutation and provides an encoder resolution of 4096 pulses per revolution.
Internal Product Review
The PMB32D-00116-00 is a Pacific Scientific PMB Series brushless servomotor built in a NEMA Size 34 frame for dependable motion control integration. A digital encoder with commutation and 4096 ppr resolution support accurate feedback and smooth servo response, a strong combination for precise automation duty.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB32D-00116-00 is a brushless servomotor manufactured by Pacific Scientific and assigned to the PMB Brushless Servomotors series. Designed for closed-loop actuation, it converts drive commands into controlled rotary motion for pick-and-place axes, indexing tables, and packaging equipment. By using electronic commutation instead of brushes, the motor supports high cycle counts with minimal service demands in industrial automation cells. That combination makes it suitable for repetitive start-stop duty where accurate position feedback and smooth torque response are required. Its mechanical footprint follows common frame conventions, which helps it fit machine layouts that use the same motor class.
The motor frame conforms to NEMA size 34, so its flange and pilot diameters match common machine brackets without adapter plates. Rotor position is monitored by a 4096 ppr incremental encoder integrated with electronic commutation, giving the drive fine resolution for velocity regulation and phase control. The motor has a nominal stall current of 5.4 ARMS and is intended for supplies up to 240 VAC. A digital encoder with commutation replaces separate Hall sensors, which reduces wiring and supports stable low-speed operation during dwell or indexing moves. Because the encoder is integrated with commutation, the feedback package stays compact and keeps motor cabling simpler than separate sensor arrangements.
System wiring is simplified by flying leads with AMP connectors, so power and feedback connections can be routed directly into the machine harness. The output shaft uses a flat rather than a keyway, enabling compact couplings and reducing backlash in belt or clamp assemblies. The motor has a stack length multiple of 2, which balances rotor inertia against continuous torque for moderate-load axes that must accelerate rapidly. The unit is supplied as a standard motor for general-purpose motion applications within this product line.









