


PMB32D-00101-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
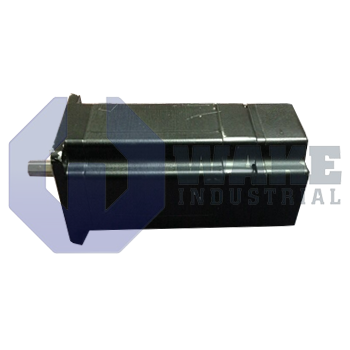
The Pacific Scientific PMB32D-00101-00 is a NEMA Size 34 brushless servomotor from the PMB Brushless Servomotors series. It features a nominal stall current of 5.4 ARMS at 240VAC maximum and a flat shaft design. The motor is equipped with Hall sensors and uses flying leads with AMP connectors.
Internal Product Review
The PMB32D-00101-00 is a Pacific Scientific PMB Series brushless servomotor built in NEMA Size 34 for dependable servo axis integration. Hall sensor feedback and a 5.4 ARMS nominal stall current support stable commutation and confident low-speed torque performance.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB32D-00101-00 brushless servomotor is built by Pacific Scientific as part of the PMB Brushless Servomotors series. Designed for closed-loop industrial automation, the unit delivers commanded torque and velocity to conveyor axes, pick-and-place heads, and light machine tools where quick step response and long service life are required. Its brushless topology reduces maintenance, while internal commutation signals let an external drive energize the coils precisely and keep position error low during continuous or incremental moves. Because electronic commutation replaces brushes and a mechanical commutator, wear at the current transfer point is reduced and routine service demands are lower.
Mechanical and electrical interfaces follow widely adopted standards. The frame is rated at NEMA Size 34, so the pilot diameter, bolt circle, and shaft center height match common gearboxes and motor mounts. Power exits through flying leads terminated with AMP connectors, allowing crimped harnesses to plug directly into cabinet wiring without an intermediate terminal strip. A trio of Hall sensors inside the stator supplies commutation feedback to typical 120-degree brushless drives. With a line supply of up to 240 VAC, the motor can sustain a nominal stall current of 5.4 ARMS. This current level helps determine continuous torque output and supports proper drive sizing during low-speed holding or high-friction moves.
The output end uses a flat shaft, simplifying rigid coupling to pulleys or gears that rely on setscrews rather than keys. Magnetic stack depth is increased by a stack length multiple of 2, which raises torque density without changing the mounting footprint. It is categorized as a standard motor, so its dimensions, insulation system, and winding constants follow the baseline PMB family configuration. The shaft form also makes alignment with compact couplings easier when the driven load has limited installation space.









