


PMB31D-10201-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
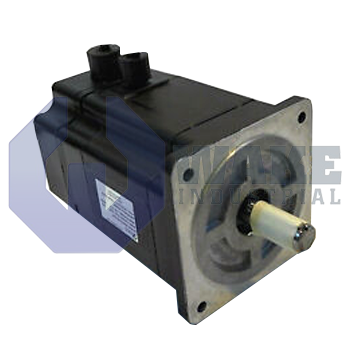
The Pacific Scientific PMB31D-10201-01 is a NEMA Size 34 servomotor with a round shaft and flying leads with MS connectors. Part of the PMB Brushless Servomotors series, it features a Hall sensor and offers a nominal stall current of 5.4 ARMS at 240Vac. This model includes a shaft seal and has a stack length multiple of 1.
Internal Product Review
The PMB31D-10201-01 is a Pacific Scientific PMB Series brushless servomotor with a NEMA Size 34 frame and Hall sensor feedback. Flying leads with MS connectors and a shaft seal support straightforward installation and dependable service in motion systems.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB31D-10201-01 is a brushless servomotor produced by Pacific Scientific and assigned to the PMB Brushless Servomotors series. As a rotary actuator, it converts electrical power into controlled torque and speed for positioning axes, feeders, or indexing tables within industrial automation cells. The unit uses permanent-magnet field excitation and electronic commutation, allowing tight velocity regulation without mechanical brushes. Because the design is brushless, there are no brushes to wear during normal operation, which helps support consistent motion over repeated duty cycles. When paired with a matched drive, the motor can support repeatable starts, stops, and speed changes in assembly, packaging, and material-handling equipment.
The motor occupies a NEMA Size 34 frame, and its 3.4-inch mounting pattern aligns with standard interfaces used on mid-power servo stages. Power and feedback are routed through flying leads with MS connectors, facilitating cable harnesses that terminate directly at panel bulkheads while maintaining environmental sealing. This connection style also helps simplify routing where cable space is limited around the motor body. Rotor position information is supplied by an integral Hall sensor, giving the drive commutation signals every 60 electrical degrees for rapid startup and fault detection. Under stall conditions at 240 VAC, the winding draws 5.4 ARMS, a value that helps size the drive and evaluate thermal loading during high-torque operation.
For mechanical adaptation, the motor is cataloged as a PMB series brushless servomotor. The order code specifies a factory-installed shaft seal, which blocks lubricant migration and airborne contaminants at the output journal. Torque is transmitted through a round shaft, allowing the use of collars, pulleys, or couplings where a keyed interface is not required. The magnetic assembly uses a stack length multiple of 1, so the active core remains compact and helps keep rotor inertia low. That lower inertia can support faster response during short indexing moves and frequent direction changes. The plain output format also leaves coupling selection open for applications that need a simple, adaptable mechanical interface.









