


PMB31D-00116-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
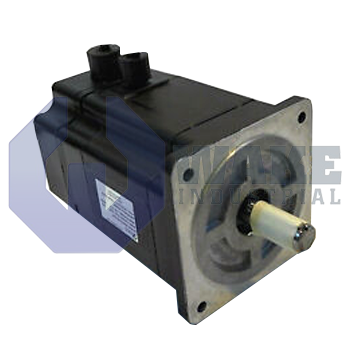
The Pacific Scientific PMB31D-00116-01 is a brushless servomotor from the PMB Brushless Servomotors series and is built in the NEMA Size 34 frame. It features a digital encoder with commutation, a resolution of 4096 pulses per revolution, and uses a flat shaft design. This motor has a nominal stall current of 5.4 ARMS at 240 VAC and is equipped with flying leads with AMP connectors.
Internal Product Review
The PMB31D-00116-01 is a Pacific Scientific PMB Series brushless servomotor in a NEMA Size 34 frame. Digital encoder commutation and 4096 ppr feedback support precise positioning and smooth servo response, a strong combination for controlled motion applications.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB31D-00116-01 is a brushless servomotor built by Pacific Scientific for the PMB Brushless Servomotors series. As a permanent-magnet, electronically commutated motor, it provides closed-loop torque and speed control for positioning tables, pick-and-place heads, and other motion axes that require repeatable response under varying mechanical loads. In an automation line, it pairs with a compatible servo drive to convert commanded current into coordinated rotary motion, supporting smooth acceleration and stable speed regulation during repetitive industrial cycles. This type of motor is commonly used where accurate starts, stops, and short settling times are needed throughout continuous machine operation.
The motor’s frame is classified as NEMA Size 34, indicating a 3.4-inch square mounting face that fits standardized gearboxes or machine plates. At 240 VAC, the winding can sustain a nominal stall current of 5.4 ARMS, which indicates the continuous torque level the drive must support without thermal overload. Power and feedback exit the housing through flying leads with AMP connectors, allowing cable routing through moving tracks instead of fixed panel connectors. Rotor position is reported by a 4096 ppr incremental encoder, and the feedback device is a digital encoder with commutation, so the drive receives both fine position data and phase-reference signals from one assembly.
The output shaft uses a flat shaft profile, providing a secure surface for set-screw couplings while keeping rotational inertia low. This shaft style suits compact couplings that rely on clamping or set screws rather than a keyed hub. A factory-installed shaft seal helps block coolant spray or fine particulates from reaching the front bearing, and the magnetic core uses a stack length multiple of 1. Encoder commutation includes U, V, and W marker tracks, which let the drive align phase currents without a separate resolver.









