


PMB31B-20101-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
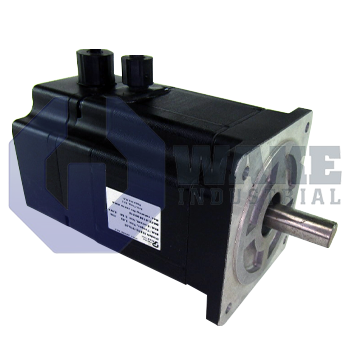
The Pacific Scientific PMB31B-20101-00 is a standard brushless servomotor from the PMB Brushless Servomotors series. This NEMA Size 34 motor features a square key shaft design and flying leads with AMP connectors. It is equipped with Hall sensors and has a nominal stall current of 2.7 ARMS at 240VAC.
Internal Product Review
The PMB31B-20101-00 is a PMB Series brushless servomotor built in a NEMA Size 34 frame. Hall sensor feedback and a square key shaft support dependable commutation and secure mechanical coupling in motion assemblies. Flying leads with AMP connectors simplify integration, and the 2.7 ARMS nominal stall current supports solid torque production.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB31B-20101-00 is a brushless servomotor produced by Pacific Scientific in the PMB Brushless Servomotors series. It converts electrical energy into controlled rotary motion for indexing tables, pick-and-place heads, and other position-critical axes used in automated machinery. The motor is intended for compact servo systems where permanent-magnet efficiency supports limited installation space. By supplying continuous torque without brushes, the unit reduces maintenance needs and provides commutation signals for closed-loop velocity and position control in general industrial automation. Its operating profile suits machinery that depends on repeatable starts, stops, and directional changes throughout normal cycle operation.
Mechanically, the frame conforms to the NEMA Size 34 outline, so the bolt pattern and pilot diameter match many standard servo gearheads and brackets. When stalled at rated temperature, the winding draws 2.7 ARMS from a 240 VAC supply. All phase, ground, and sensor conductors exit as flying leads with AMP connectors, which allows connection without opening the motor housing. Rotor position feedback is supplied by an integrated Hall sensor that generates three square-wave signals for six-step commutation. The unit is built as a standard motor, with no special coatings, windings, or bearing changes.
The output shaft uses a square key, providing positive torque transmission to pulleys or couplings without relying on friction alone. Active magnetic length uses a stack length multiple of 1, which is the shortest option and helps reduce rotor inertia during rapid starts and stops. The short magnetic stack supports quick speed changes on indexing moves and other repetitive positioning tasks. The keyed shaft and electronic feedback make the motor suitable for controlled motion where stable commutation and repeatable acceleration are required. This arrangement is useful in compact axes that need responsive motion without a large motor envelope.









