


PMB31B-10214-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
5 Minutes
20 Seconds
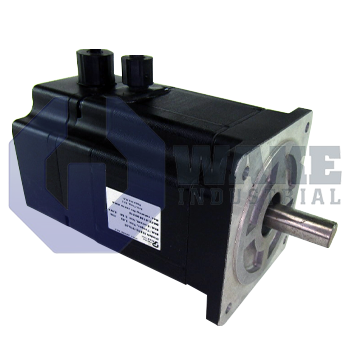
The Pacific Scientific PMB31B-10214-01 is a brushless servomotor from the PMB Brushless Servomotors series with a NEMA size 34 frame and round shaft design. It features a digital encoder with commutation, 2048 pulses per revolution encoder resolution, and flying leads with MS connectors. The servomotor has a nominal stall current of 2.7 ARMS at 240 VAC max and includes a shaft seal customization.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB31B-10214-01 is a brushless servomotor manufactured by Pacific Scientific as part of the PMB Brushless Servomotors series. Designed for closed-loop motion control, the unit converts electrical energy into regulated torque so that pick-and-place modules, small indexers, and ancillary packaging axes meet commanded positions under PLC supervision. When paired with an external servo drive, it supplies the rapid acceleration, repeatable positioning, and continuous-duty operation required in modern automated equipment.
The motor occupies the NEMA Size 34 frame, letting it bolt directly into machinery that already follows this standardized mounting pattern. At a 240 V AC bus, the winding reaches a nominal stall demand of 2.7 ARMS, which is the continuous current the drive must source to hold load torque without overheating. Rotor position is returned through an internal feedback device that delivers 2048 ppr. This resolution supports fine velocity and micro-position loops without external gear reduction. Power, feedback, and commutation lines exit the housing as flying leads with MS connectors, streamlining cable runs inside panels while keeping service disconnects outside the motor. Servo alignment is simplified further because the sensing element is a digital encoder with commutation, so phase information is available to the drive at power-up.
For added environmental protection, the motor includes a shaft seal, preventing lubricant migration and helping limit dust ingress at the coupling interface. A round shaft is supplied instead of a keyed or splined variant, allowing the use of clamp-style hubs with low balance error. Magnetic stack length is fixed at a stack length multiple of 1, which gives the motor the inertia and torque profile intended for lighter loads. This arrangement supports direct-coupled hubs in compact servo axes.









