


PMB31B-10116-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
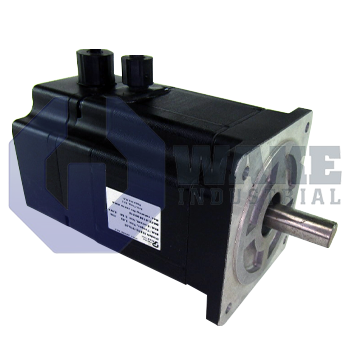
The Pacific Scientific PMB31B-10116-01 is a brushless servomotor from the PMB Brushless Servomotors series with a NEMA Size 34 frame and a round shaft design. It features a digital encoder with commutation at 4096 pulses per revolution and flying leads with AMP connectors. This motor has a nominal stall current of 2.7 ARMS at 240VAC maximum and includes a shaft seal customization.
Internal Product Review
The PMB31B-10116-01 is a PMB Series brushless servomotor in a NEMA Size 34 frame. Digital encoder with commutation and 4096 ppr feedback support clean positioning response and dependable servo tuning. Flying leads with AMP connectors simplify integration, and the shaft seal adds practical protection for demanding motion assemblies.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB31B-10116-01 brushless servomotor is produced by Pacific Scientific as part of the PMB Brushless Servomotors series. It converts electrical energy into controlled rotary motion for positioning tasks in automated machinery, pick-and-place heads, and packaging axes. The motor is intended for closed-loop servo axes where commanded speed and position must be followed accurately during indexing, transfer, or continuous-feed motion. A permanent-magnet rotor works with electronic commutation to deliver repeatable torque without brushes, which reduces wear associated with brush contact. When paired with a compatible drive, the motor supports the velocity and position control needed for machine tools, conveyors, and other programmed motion systems.
Its frame follows the NEMA Size 34 envelope, so it mounts directly to standard 3.4-inch face patterns used in compact machinery. When operated from a 240 VAC amplifier, the winding can sustain a nominal stall current of 2.7 ARMS. That current rating indicates the thermal operating point available during continuous servo duty. Rotor position feedback comes from an optical encoder rated at 4096 ppr, which provides 12-bit incremental resolution for accurate position updates and stable speed regulation. Phase conductors exit the housing as flying leads with AMP connectors, allowing direct cable mating or splicing without opening the motor. Because the motor uses a digital encoder with commutation, no separate Hall sensors are required for phase alignment.
A shaft seal is available to reduce the risk of dust or fluid entering along the output end in harsher service areas. The motor uses a round shaft, which fits clamp collars, pulley hubs, and couplings that rely on friction instead of keys, and this style can simplify alignment in compact assemblies. Internal laminations use a stack length multiple of 1, giving the motor the shortest magnetic core in this line and helping keep inertia low for responsive acceleration. The short core is suited to applications that benefit from quick speed changes and frequent directional reversals.









