


PMB31B-10116-00 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
6 Minutes
59 Seconds
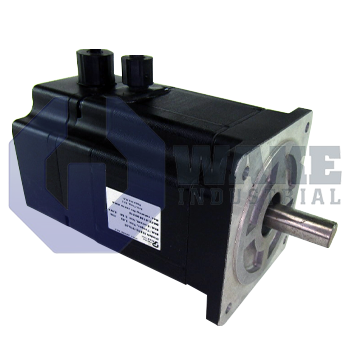
The Pacific Scientific PMB31B-10116-00 is a standard motor from the PMB Brushless Servomotors series with a NEMA Size 34 frame and a round shaft design. It uses flying leads with AMP connectors and features a digital encoder with commutation, offering 4096 pulses per revolution. The nominal stall current at 240 VAC is 2.7 ARMS.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB31B-10116-00 is a brushless servomotor manufactured by Pacific Scientific and supplied within the PMB Brushless Servomotors series. Designed for closed-loop motion, the motor converts drive current into precise rotary torque for automated pick-and-place units, indexing tables, and similar equipment. Its integrated feedback package provides the position data required by modern servo amplifiers and avoids the brush wear associated with brushed motor designs. This arrangement makes the motor suitable for servo axes that need repeatable motion, steady speed regulation, and accurate response to changing commands.
The motor draws a nominal stall current of 2.7 ARMS at 240 VAC, which sets the current level the drive and conductors must support at stall. Accurate positioning is enabled by an encoder resolution of 4096 ppr, which sends 4096 incremental pulses per revolution to the controller. A frame in NEMA size 34 gives the housing a standard 3.4-inch square mounting pattern used in many industrial assemblies. Power and feedback are routed through flying leads with AMP connectors, which allows direct wiring to the drive and feedback interface. The sensing device is a digital encoder with commutation, so the motor provides both incremental position data and the electrical phase information needed for controlled current switching.
The unit is supplied as a standard motor, so it follows the normal dimensions and winding values used for this series. A round shaft supports clamp collars or sleeve hubs where a keyed shaft is not required. The magnetic core uses a stack length multiple of 1, which is the shortest option in the line and helps keep rotor inertia low for quick acceleration. This shorter stack can be useful on compact axes where reduced rotating mass helps improve response during repeated starts, stops, and direction changes.









