


PMB31B-00116-01 Pacific Scientific
Wake Industrial LLC is not an authorized distributor of this product.
- Straightforward Pricing: No Rush Fees, No Credit Card Fees
Current response time:
6 Minutes
35 Seconds
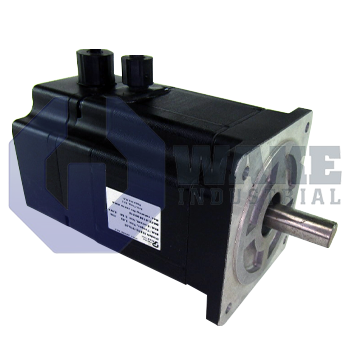
The Pacific Scientific PMB31B-00116-01 is a brushless servomotor from the PMB Brushless Servomotors series with a NEMA Size 34 motor. It includes a shaft seal for customization and features a digital encoder with commutation and a 4096 ppr resolution. This servomotor also comes with flat shaft design and flying leads with AMP connectors.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The PMB31B-00116-01 is a brushless servomotor manufactured by Pacific Scientific and supplied within the PMB Brushless Servomotors series. As a permanent-magnet actuator for closed-loop drive systems, it converts electrical energy into precisely regulated torque and speed for pick-and-place axes, electronic assembly heads, and other positioning duties inside automated equipment. Its compact construction and built-in feedback allow direct integration with matching power stages and third-party servo controllers, providing accurate motion profiles while minimizing maintenance requirements common to brushless designs.
Mechanical and electrical ratings center on a frame classified as NEMA Size 34, giving the motor a 3.4-inch square flange that is compatible with standard gearboxes and mounts. Under worst-case thermal conditions at 240 VAC, the winding draws a nominal stall current of 2.7 ARMS, a value the drive must supply continuously for static torque production without exceeding temperature limits. Position feedback is delivered by an optical encoder producing 4096 ppr of incremental resolution, enabling tight positional interpolation during servo loops. Power and signal conductors exit the stator as flying leads with AMP connectors, simplifying field termination where space restrictions prevent right-angle plugs. The motor’s commutation reference is managed internally by a digital encoder with commutation, removing the need for separate Hall devices and improving phase accuracy.
For environmental protection, this build includes a shaft seal that helps block dust or coolant from migrating along the output journal. The journal itself follows a flat shaft design, offering a broad bearing surface for set-screw couplings and eliminating keyways. Magnetic stack height is governed by a stack length multiple of 1, so torque scaling is achieved without altering the frame envelope. This layout supports compact motor installation where coupling space and contamination control are both important.









