RZP01.1-K1 Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911200601
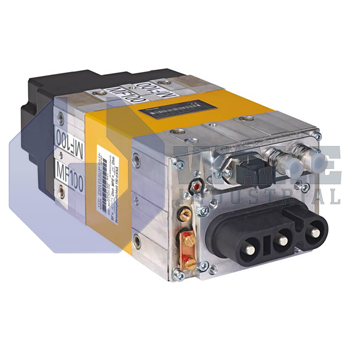
Ask for AvailabilityThe Bosch Rexroth Indramat RZP01.1-K1 is an option module from the RZP Option Modules series. It features a CAN Bus interface with a default baud rate of 500 kbaud and includes connector X13 for communication. The module designates pins for CAN High, CAN Low, and signal ground, and does not provide galvanic isolation.
Internal Product Review
The RZP01.1-K1 is a CAN Bus option module with an X13 connector for clean integration into Bosch Rexroth Indramat control architectures. Default communication settings of 500 kbaud and Tx identifier 176 support efficient commissioning on established CAN networks. A 0.1 s Rx timeout with fault watchdog behavior adds dependable message supervision, making the module a strong choice for stable fieldbus integration.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The RZP01.1-K1 option module is produced by Bosch Rexroth Indramat and belongs to the RZP Option Modules series. It mounts inside Rexroth drive controllers to provide a CAN communication interface that exchanges process data words between the drive and higher-level PLCs or motion coordinators. By adding this board, an engineer can link a drive to a CAN network without using external gateways, keeping wiring short and diagnostics centralized.
All network wiring is terminated on connector X13, where pin 1 carries the CAN high signal, pin 2 carries CAN low, and pin 3 is signal ground. At power-up the module initializes with a default speed of 500 kbaud, a value that defines the maximum bit transfer rate on the bus and must match every other node. Incoming telegrams are accepted only when their identifier equals 160; this identifier lets the drive filter messages meant for its control word. If no valid frame is received within 0.1 s the receive watchdog triggers, and the module places the axis in the protective state denoted as Fault, preventing uncontrolled motion.
For transmission tasks, the module issues status words under identifier 176. The transmit process data clock is factory-set to 254 ms, so the drive publishes its status roughly four times per second unless modified through parameterization. There is no galvanic barrier between the CAN signals and the internal electronics, indicated by the value No for isolation; therefore the system designer must ensure a common reference potential through the signal ground line. Because the interface conforms to the CAN Bus standard, it supports standard differential signaling and arbitration rules, allowing the module to integrate with third-party controllers that observe ISO 11898 while still retaining the pin assignment and timing described above.