


MKD071B-061-GP0-KN Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911261314
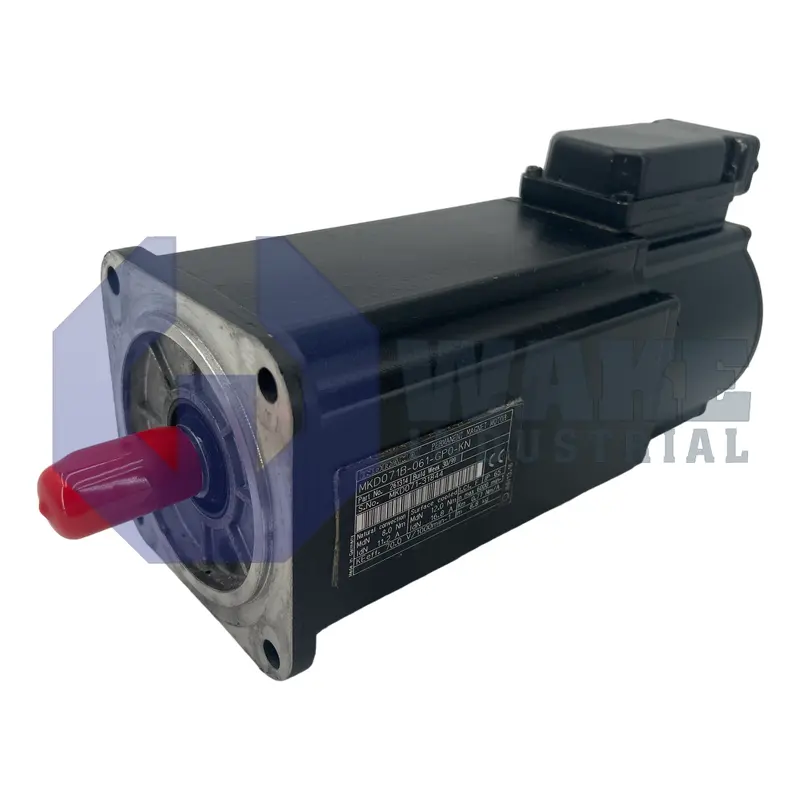
The Bosch Rexroth Indramat MKD071B-061-GP0-KN is a servo motor from the MKD Synchronous Motors series, featuring a 115 mm flange size and a 95 mm centering diameter. This motor provides a continuous torque at standstill of 8.0 Nm, has resolver feedback for position detection, and uses a connection box on Side B. The design includes a shaft with keyway and does not have a holding brake.
Internal Product Review
The MKD071B-061-GP0-KN is a Bosch Rexroth Indramat synchronous servo motor featuring a 95 mm centering diameter and a 115 mm flange size, making it well-suited for medium-scale automation systems. With resolver feedback for relative position detection and a continuous standstill torque of 8.0 Nm, this motor delivers accurate and stable performance in precision motion control applications. The shaft with keyway enhances secure coupling, highlighting its dependable integration into drive systems.
 Have a part to sell?
 Wake Industrial Warranty
To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The MKD071B-061-GP0-KN is a servo motor produced by Bosch Rexroth Indramat as part of the MKD Synchronous Motors series. It converts regulated drive current into repeatable torque for positioning or velocity control inside machining centers, pick-and-place gantries, and other industrial automation assemblies. The motor belongs to size 071 in the family, placing it in the middle of the range for balancing power density and installation footprint.
Mechanical interface dimensions begin with a centering diameter of 95 mm that aligns the housing to the mounting surface, while a flange size of 115 mm sets the bolt circle for the machine frame. The motor delivers a continuous standstill torque of 8.0 Nm, allowing the 071 frame to hold constant load without overheating. Motion feedback is provided by a resolver feedback device, giving analog sine-cosine signals for closed-loop control, and rotor power is transferred through a shaft with keyway that secures couplings against slip. These features define the static load capability and the precision feedback path required for the drive to maintain commanded positions.
Electrical terminations sit on the motor’s rear because the power and feedback interfaces are oriented toward Side B and are collected in a Connection box for strain-relieved cabling. The unit is assembled without a holding brake, so any load must be locked externally when power is removed. Its electromagnetic profile is identified by winding code 061, which establishes phase resistance and current limits for the compatible drive, while motor length B and the relative position detection scheme minimize inertia and simplify homing routines. Together, these layout details allow the 071 size servo to be inserted into tight enclosures where precise motion is needed and maintenance space is limited.









