


KSM02.1B-041C-42N-M1-HG0-ET-L3-D7-NN-FW Bosch Rexroth Indramat
Wake Industrial LLC is not an authorized distributor of this product.
MPN: R911335755
No Tariffs On US Orders- Straightforward Pricing: No Rush Fees, No Credit Card Fees
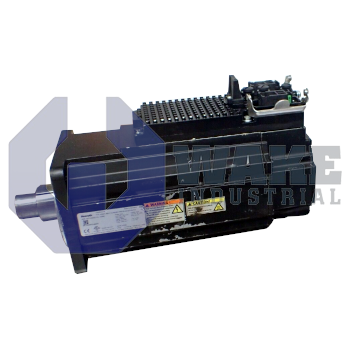
The Bosch Rexroth Indramat KSM02.1B-041C-42N-M1-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive from the KSM Motor Integrated Servo Drives series. It features a Multi-Ethernet communication protocol, Hiperface multi-turn absolute encoder, and a hybrid connector. The drive operates at a supply voltage of DC 750 V and uses natural convection for cooling.


To contact sales for pricing and lead time:
Payment Methods


Shipping Methods


Our Credentials


Product Description:
The KSM02.1B-041C-42N-M1-HG0-ET-L3-D7-NN-FW is a motor-integrated servo drive from Bosch Rexroth Indramat in the KSM Motor Integrated Servo Drives series. By combining power electronics, a communication interface, and a synchronous motor in one enclosure, the unit supports decentralized axis control in assembly lines, packaging stations, and handling gantries. It is intended to provide precise torque and speed regulation directly at the machine frame while reducing cabinet wiring and lowering the amount of heat that must be managed in a control enclosure.
Power is supplied through a DC 750 V shared bus, and all power, feedback, and network signals pass through a single Hybrid Connector, so only one cable is needed for each axis. Thermal losses are removed by natural convection, which allows the housing to remain sealed without fans or filters. Command and diagnostic data travel over Multi-Ethernet, allowing the same drive to communicate through EtherNet/IP, PROFINET, or EtherCAT networks without a hardware change. An integrated Safe Torque Off (STO) function disables the power stage internally for controlled shutdown behavior. The unit uses motor size 041 with length code C, giving it a compact format for distributed servo applications.
Rotor position is measured by a Hiperface optical encoder that provides 128 signal periods per revolution and includes a multi-turn absolute counter, so position data is retained after power is removed and restored. The motor uses winding code 42, which matches the stator winding to the internal inverter for stable current control. It also has a plain shaft with a shaft seal. The drive is supplied in a standard design with design version 1, a basic performance level controller board, and series 2 electronics. Because it does not include a holding brake, the load must be secured by an external mechanism when power is removed.









